Prabal Khare, robotics software engineer

Prabal Khare

Robotics Software Engineer · Brooklyn, New York

I build robot systems and study what happens when learned policies fail.

I build the whole robot, sensors, comms, localization, navigation, controls, operator tooling, and the deployment that proves it works. Now at NYU, working on whether learned policies can recover when they do not.

GitHub2,442 contributions in the last year

Last 5 monthsLessMore

Projects and professional experience

Ripple: An always-on site engineer for Nav2 robots

Active development2025 to present

Ripple watches a Nav2 robot, diagnoses why it stopped, and recovers inside a budget you configure, clearing costmaps, probing routes, routing around a tight spot, backing out under teleop. When the evidence says the problem is physical, it stops and asks an engineer in plain words. Every closed incident leaves a lesson attached to that place, so the same corner does not cost the same time twice.

ROS 2 Humble · Nav2 · PostgreSQL · GLM 5.3 · OpenRouter · Gazebo · RosScope · Node.js

Wren: A small, fast visuomotor policy for low-cost robot arms

Active development2026

Wren looks through a scene camera and a wrist camera, reads the joint angles, and outputs the next 1.6 s of motion for a 6-DoF SO-101 arm. 61M trainable parameters: a shared DINOv2 encoder, a transformer trunk and a flow-matching DiT action expert with trained-in real-time chunking. It trains on one 8 GB laptop GPU in about 6 hours and runs at about 110 ms per query on a Jetson Orin Nano.

PyTorch · LeRobot · DINOv2 · Flow matching · Jetson Orin Nano · CUDA graphs · SO-101

SMR300: 300 kg industrial autonomous mobile robot

Deployed2026 · Next Robotics Lab

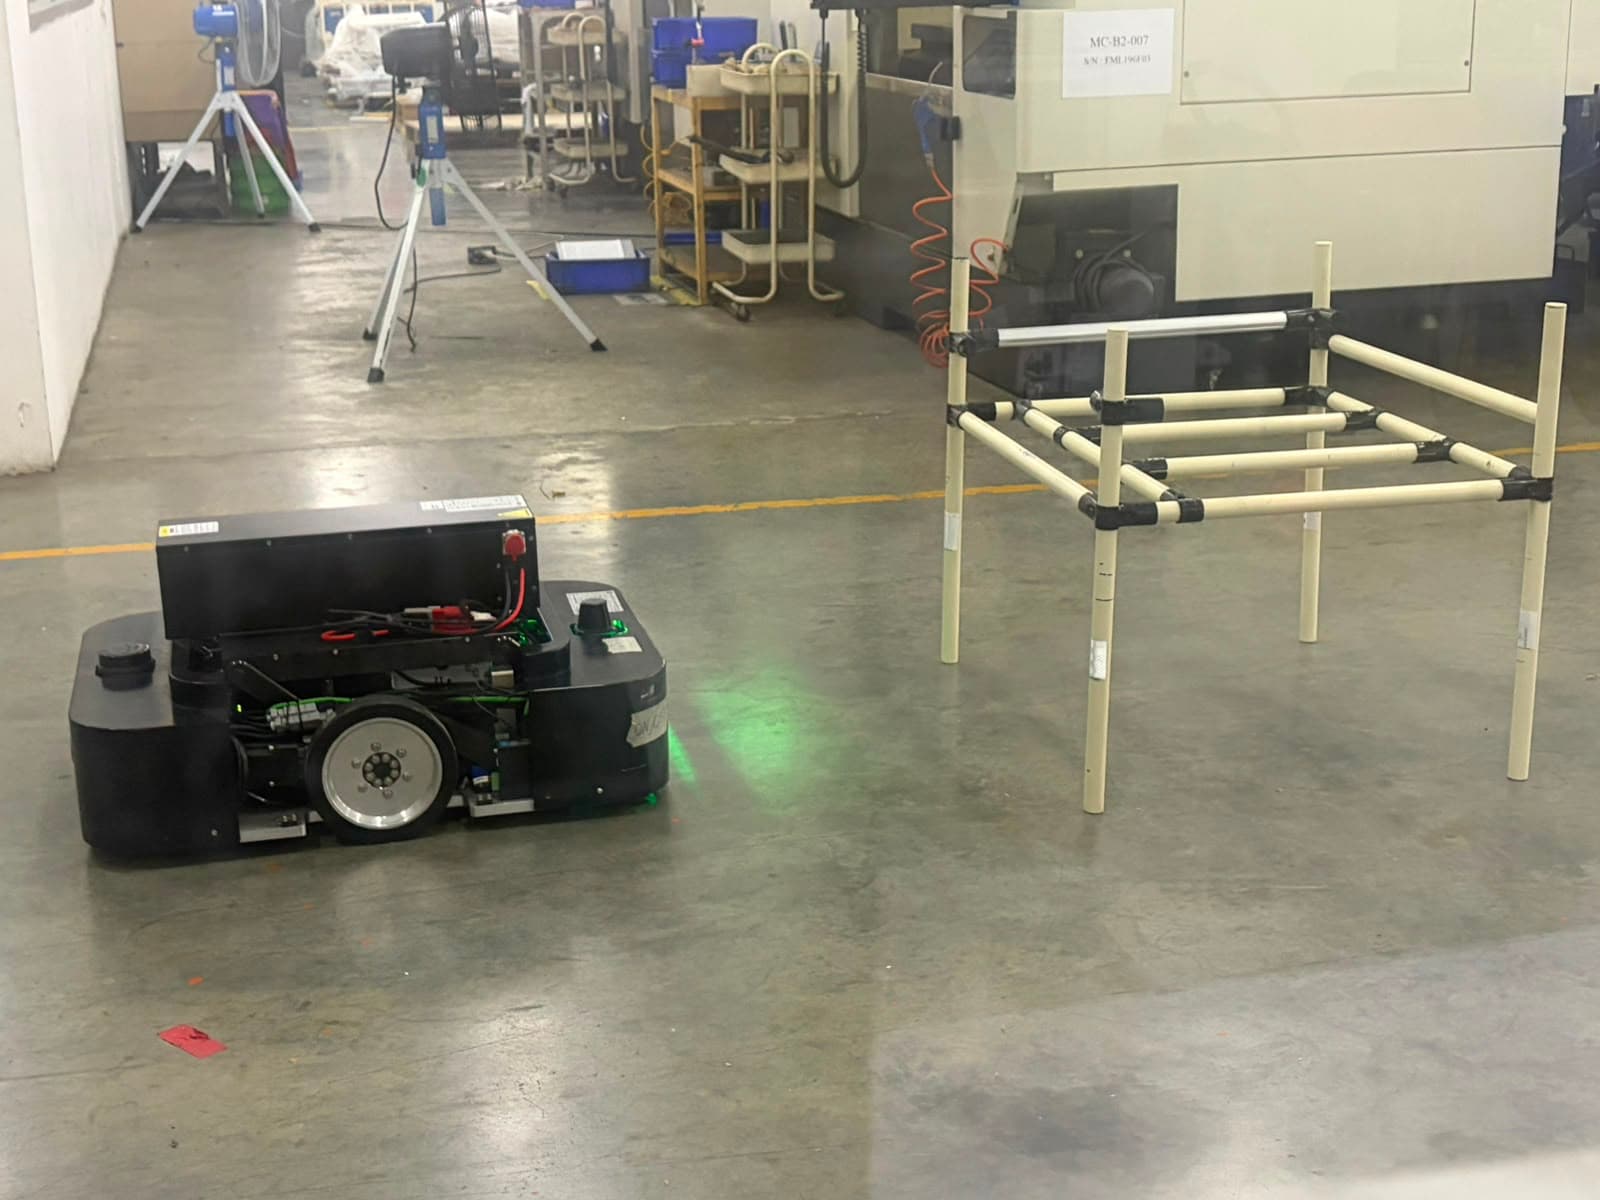
The full autonomy stack, written to be reused across a fleet, not to survive one demo. Rebuilt from a legacy ROS 1 architecture into ROS 2 Humble, validated over 300 logged trials on a live factory floor.

97% shelf docking success · 2 cm shelf docking error · 3 cm point-to-point mismatch

ROS 2 Humble · Nav2 · CANopen · CiA 402 · PGV · LiDAR · C++

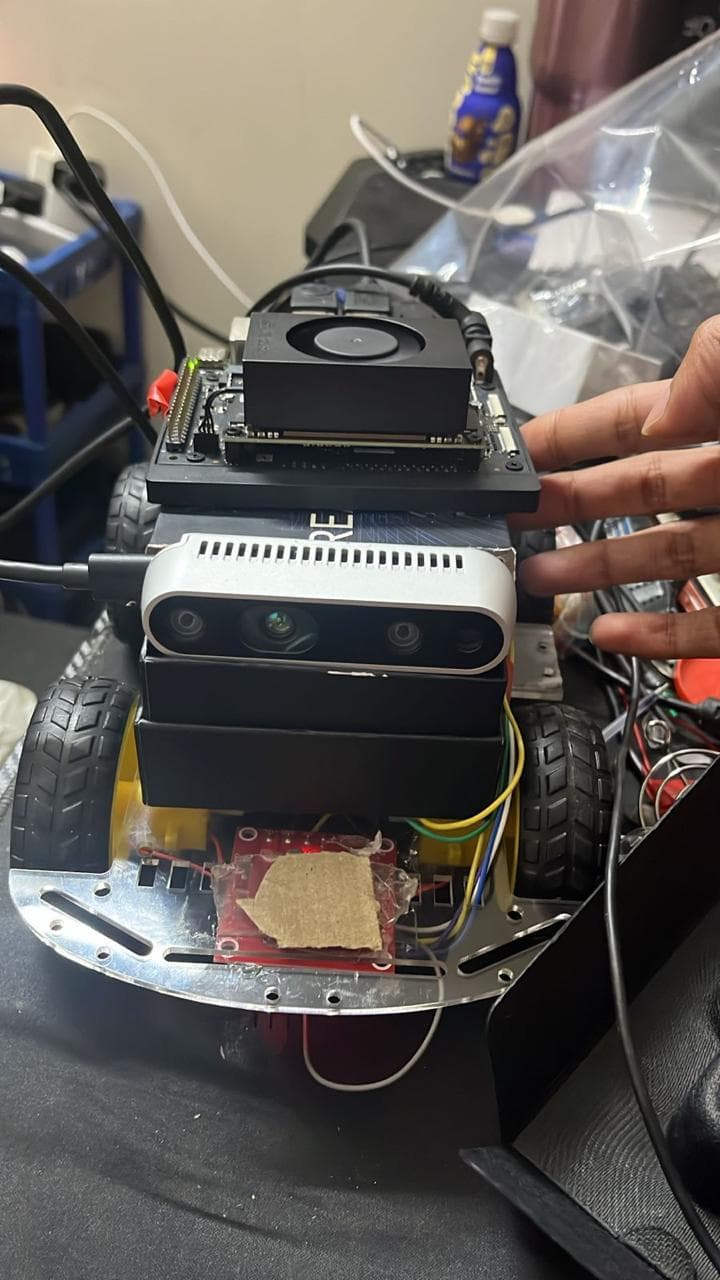
Kurat, RealSense D435i and Jetson Orin Nano on a four-wheel chassis

Kurat: Autonomous conversational robot

Active developmentPatent2025 to present

Published Indian patent application: A System for a Companion Robot, No. 202641114580. Lead inventor.

A companion robot built on a three-brain architecture that separates perception, cognition and action so each can fail and recover independently.

ROS 2 · PyTorch · YOLOv8 · Whisper · ORB-SLAM3 · Nav2 · Jetson

Case study
Details
  • Three-brain split, perception, cognition, action, for modular autonomy and reliable real-time interaction.
  • Intel RealSense D435i + Jetson Orin Nano running YOLOv8, Whisper, ORB-SLAM3 and Nav2 for perception, speech, localization and navigation.

Project MIRA: Autonomous underwater vehicle

Completed2023 to 2025

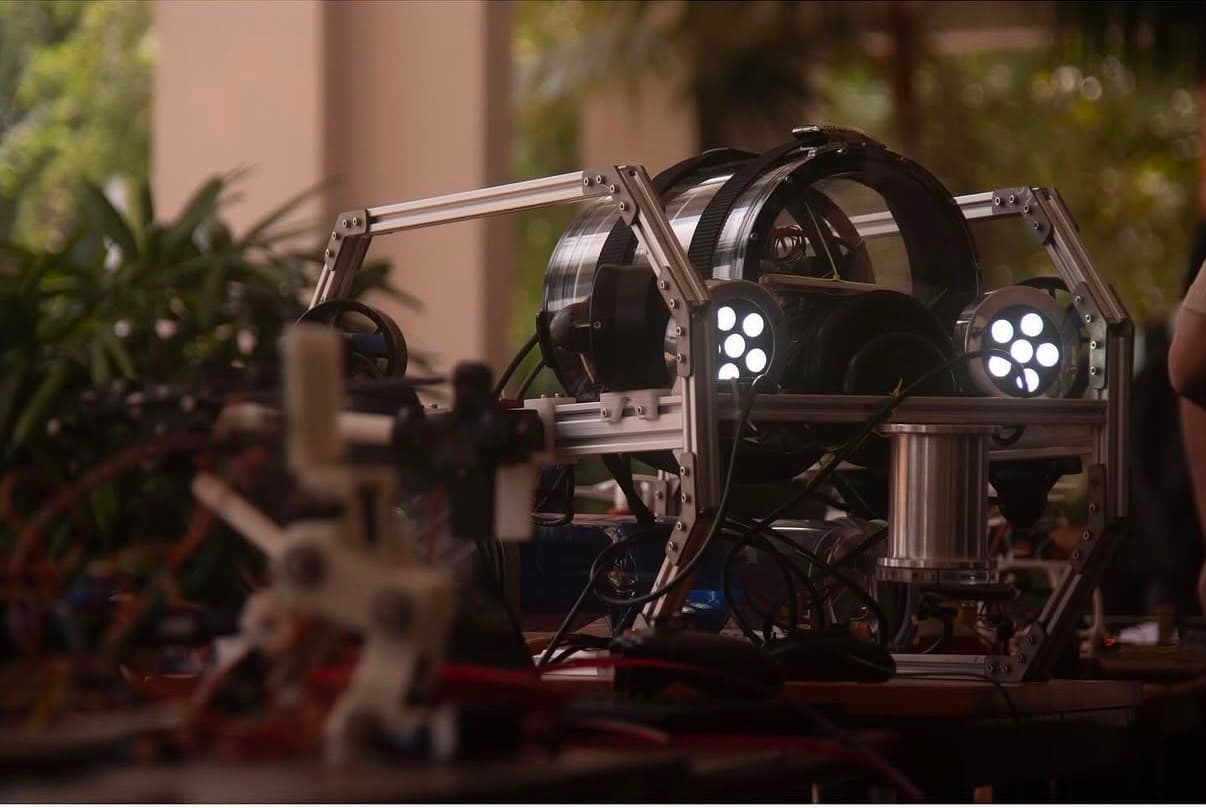
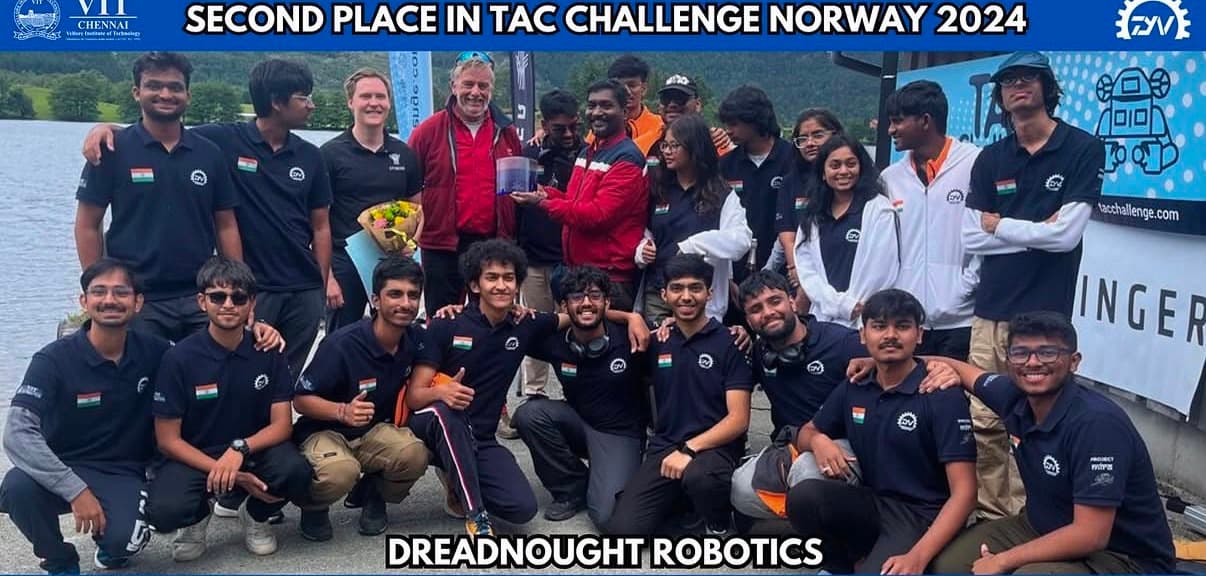
Sealed-hull AUV that took 2nd place at the TAC Challenge in Norway, 2024. I owned the electrical architecture and the MAVROS control software.

ROS · MAVROS · MAVLink · PCB · Power distribution

Case study
Details
  • Electrical architecture and power distribution inside a sealed pressure hull.
  • Hydrophone and sensor-control subsystem integration, PCB prototyping.
  • ROS / MAVROS / MAVLink control software and cross-functional test coordination.

Pushpak Viman: Victim detection from a transforming drone-rover

CompletedPatent2023 to 2025

Published Indian patent application: AI-Enabled Search-and-Rescue Robot, No. 202641035669. Lead inventor.

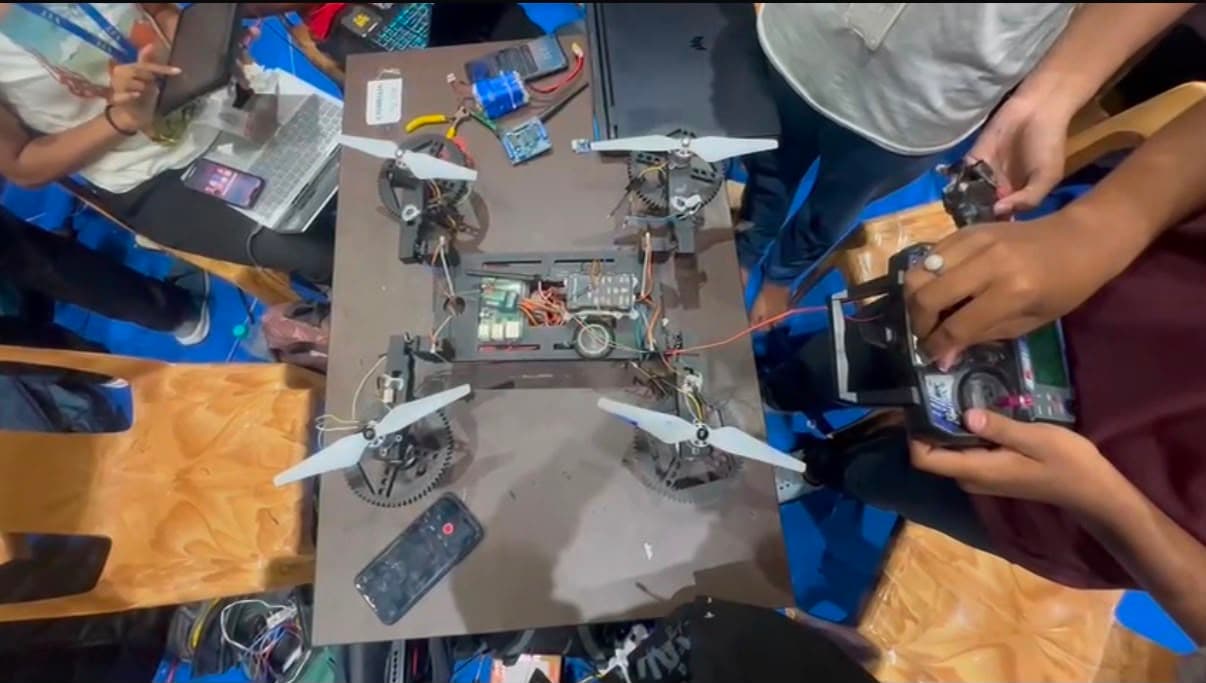
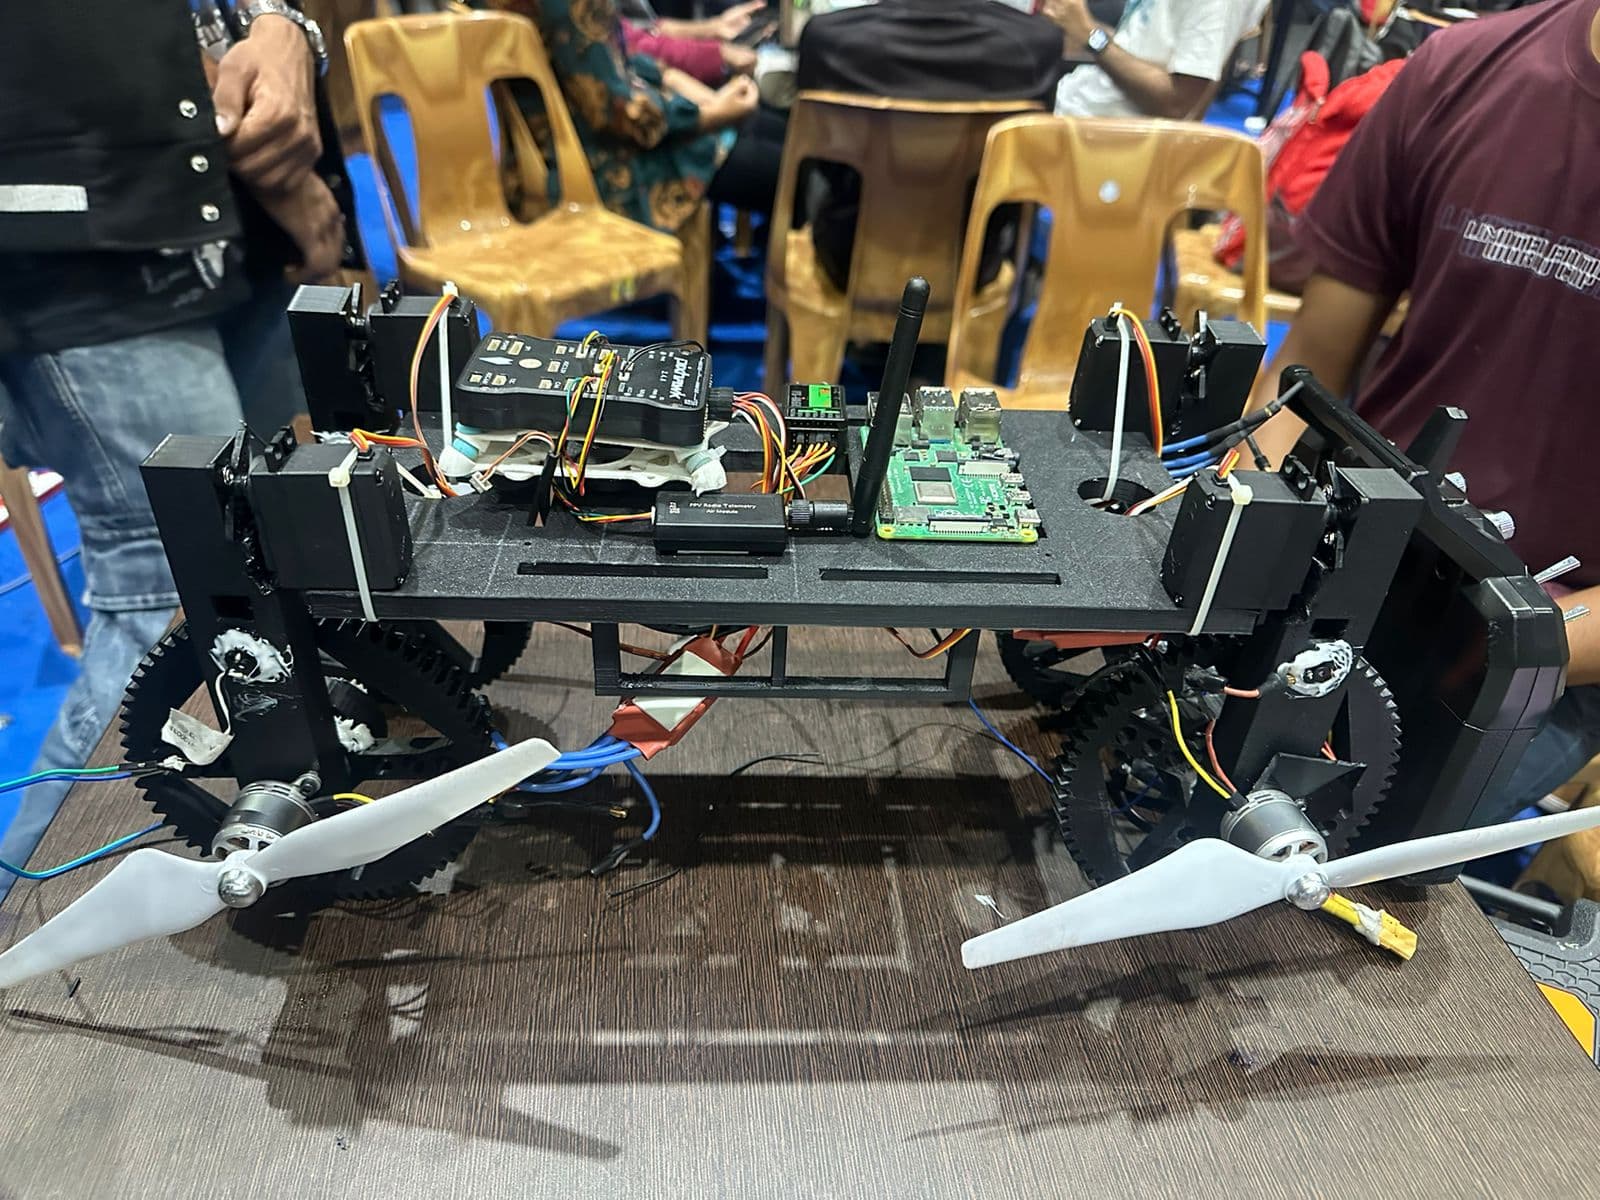
An autonomous rescue initiative: a victim-under-debris detection pipeline, and a platform whose four arms carry both propellers and geared drive wheels so it can drive where it cannot fly.

Python · OpenCV · TensorFlow Lite · YOLOv5 · MediaPipe · PyTorch

Case study Repository
Details
  • Dataset splitting and annotation conversion from Pascal VOC XML through CSV to TFRecord.
  • Detection training and real-time inference with TensorFlow Lite and YOLOv5, with bounding-box visualisation.
  • MediaPipe hand-landmark tracking for gesture-based control.
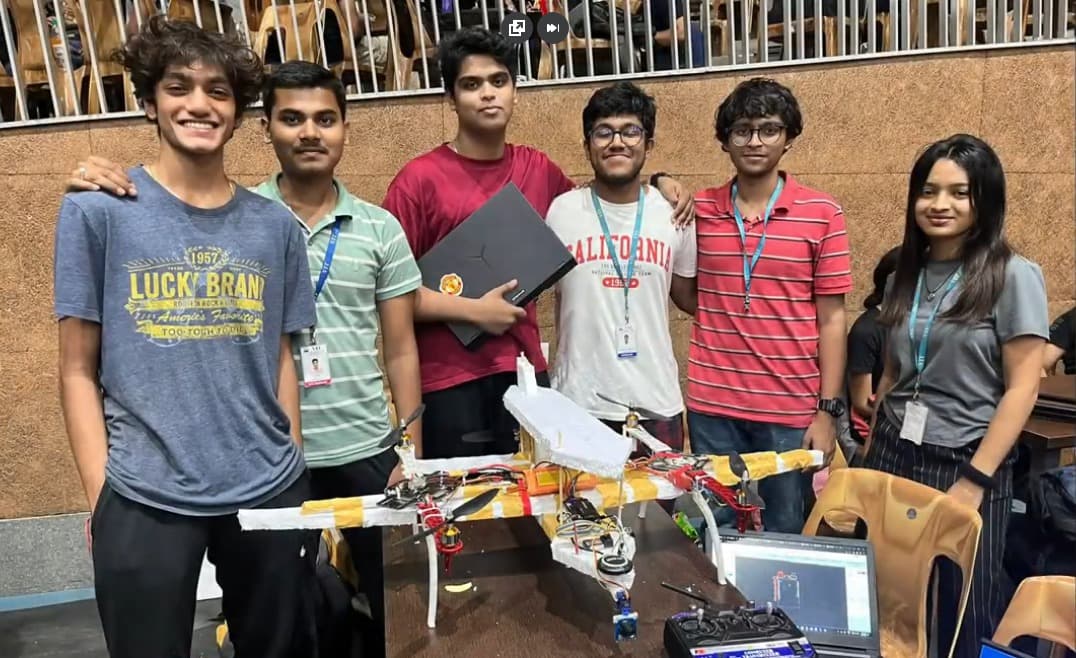
VTOL search-and-rescue quadplane, plank wing, four lift rotors, exposed avionics

Autonomous VTOL UAV: Search and rescue

Completed2023

A VTOL search-and-rescue prototype with thermal victim detection, flown on a Raspberry Pi and Pixhawk airframe. No repository, it was a prototype.

Python · MAVROS · Pixhawk · OpenCV · TFLite · YOLOv5

Case study
Details
  • Raspberry Pi + Pixhawk + MAVROS airframe with OpenCV and thermal imaging for victim detection.
  • Dataset preparation, TensorFlow Lite and YOLOv5 inference, autonomous scan patterns, custom battery management.
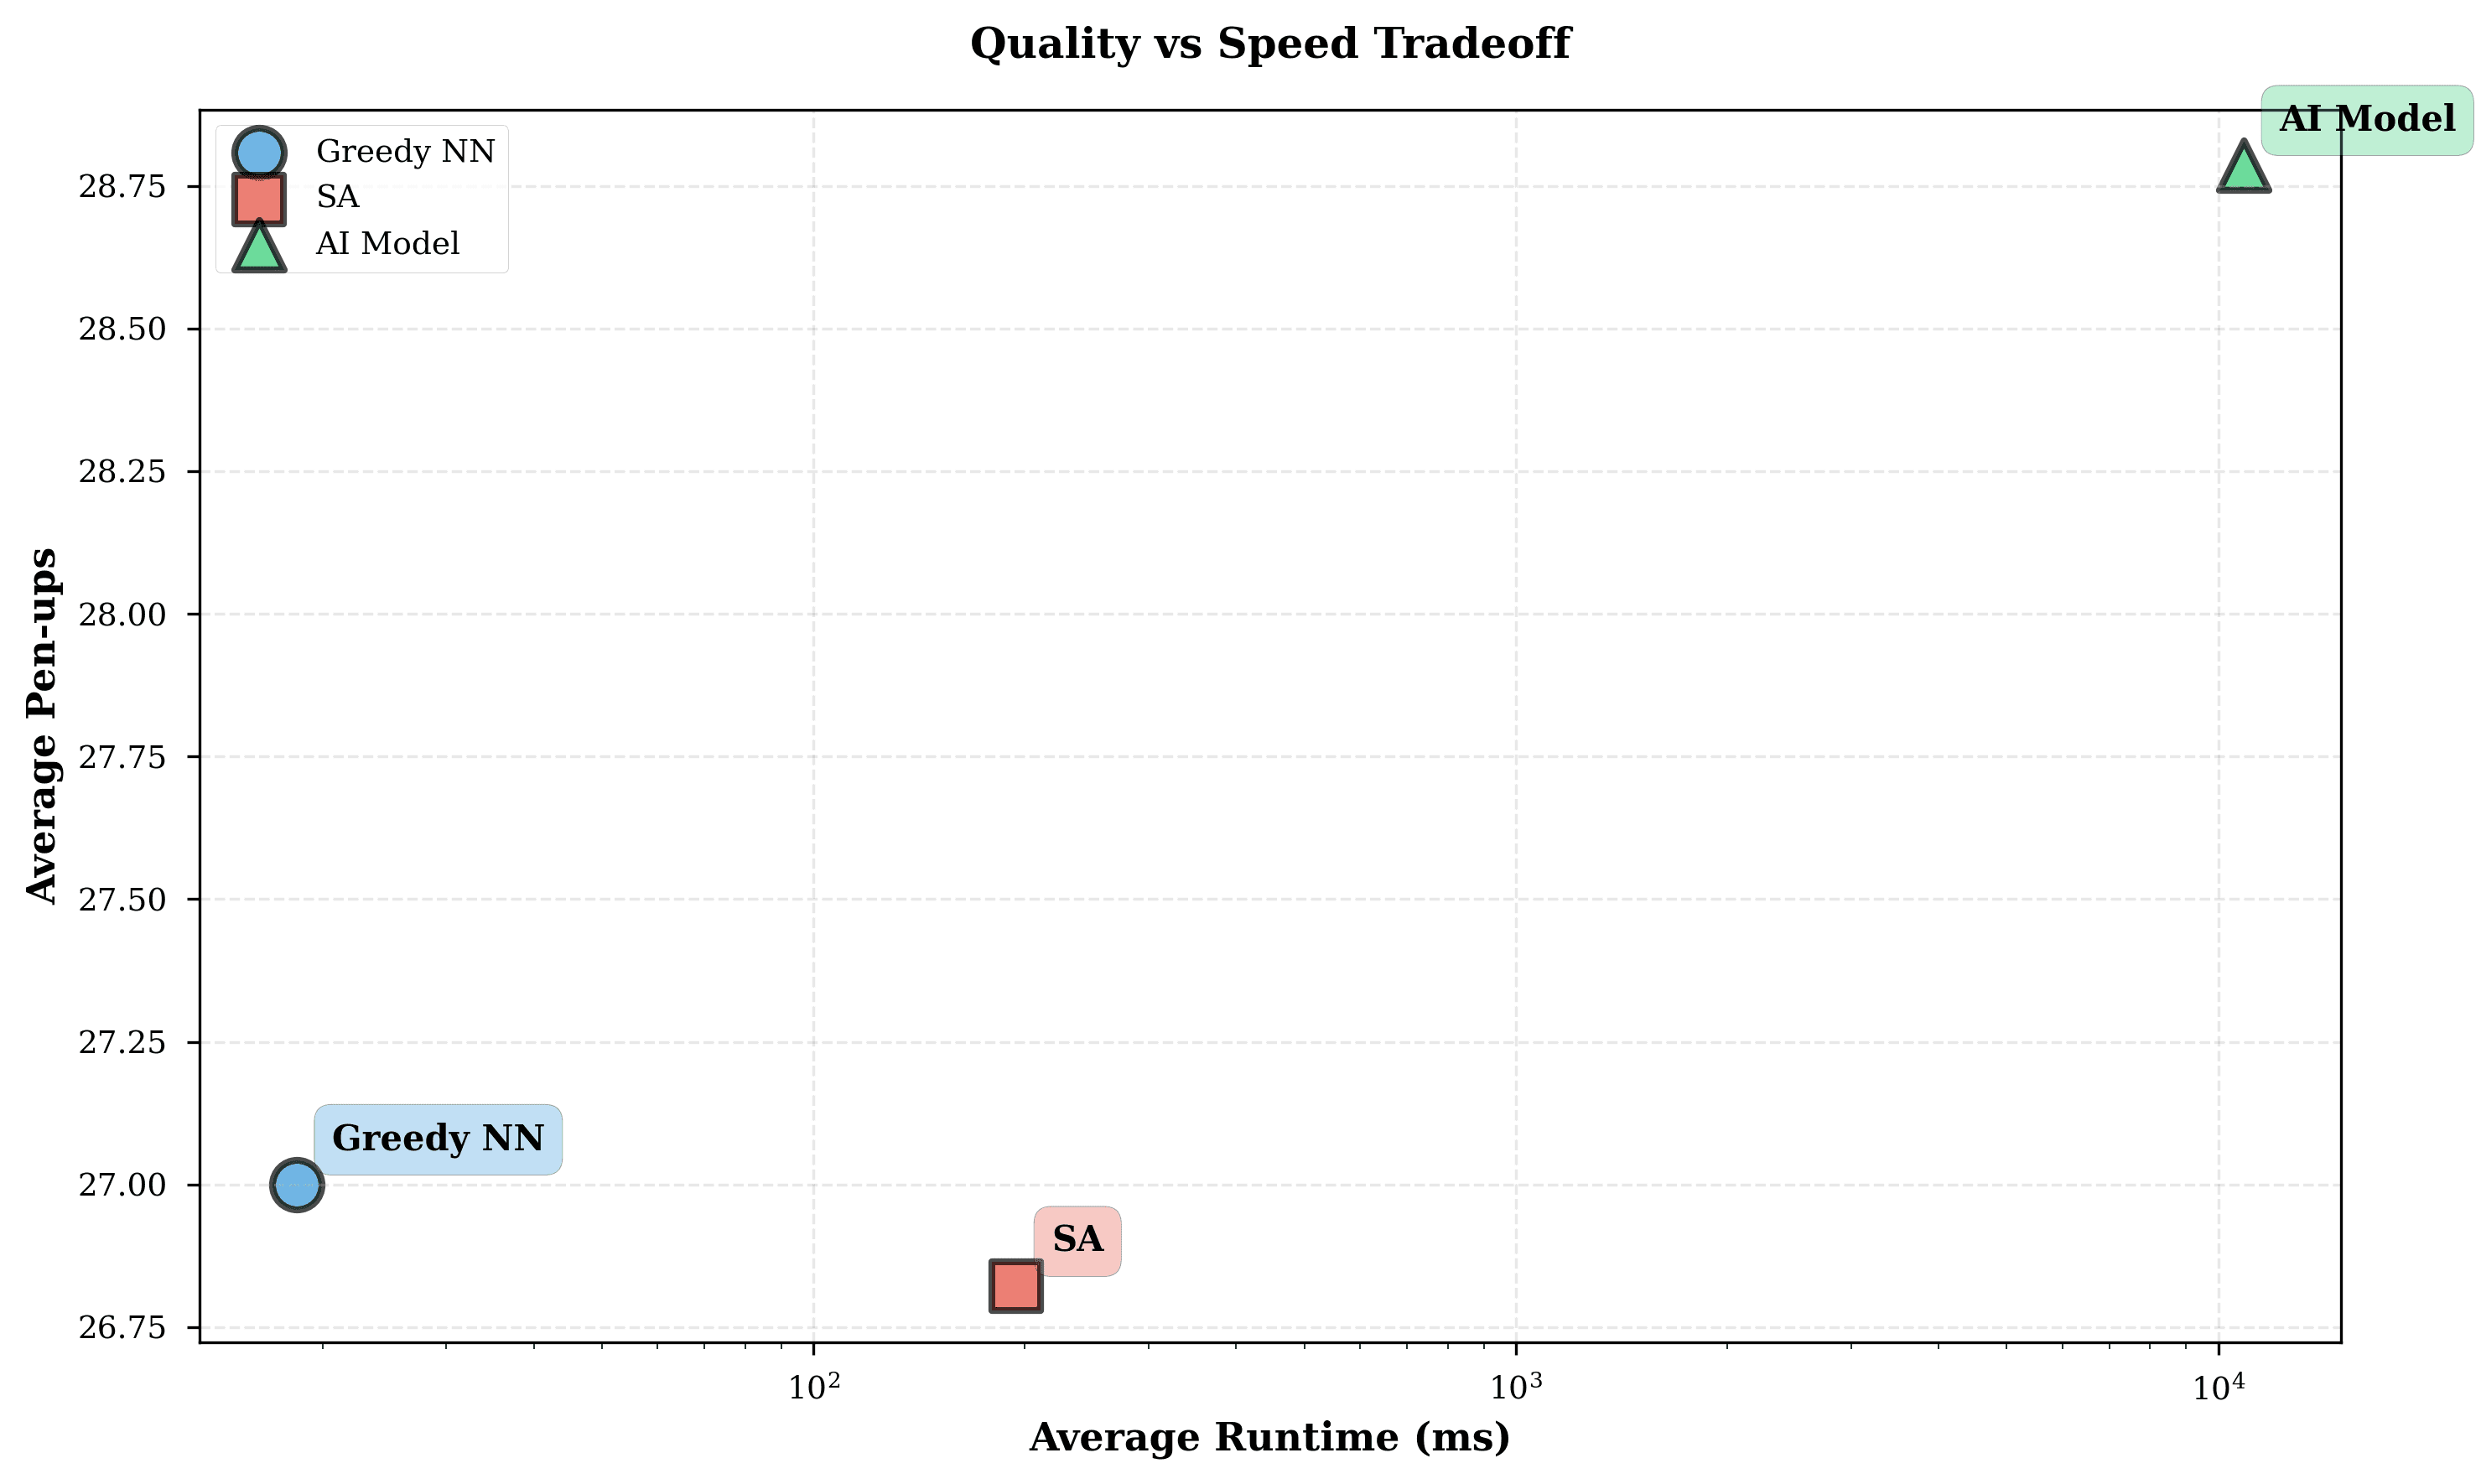
Quality against runtime across all three methods. The learned router sits where you would least want it, slowest and highest pen-up count

RobotDrawing: Learned motion planning · simulated ABB IRB140

Completed2026

Robotic drawing as a stroke-level TSP, solved by a learned router instead of a slow classical solver, same quality, roughly 20× faster.

PyTorch · PyTorch Geometric · GNN · Pointer Network · RL · CoppeliaSim · ABB RAPID

Case study Repository
Details
  • Formulated at stroke level rather than point level, with forward/reverse direction optimization to cut pen-ups and travel.
  • Graph Neural Network + Pointer Network trained in two phases: imitation learning from classical solvers, then reinforcement learning.
  • Curriculum learning scales to 300+ strokes; ~150 ms inference per drawing, matching simulated-annealing quality ~20× faster.
  • Exported as ABB RAPID and executed by a simulated IRB140 in CoppeliaSim, no physical arm has run it.
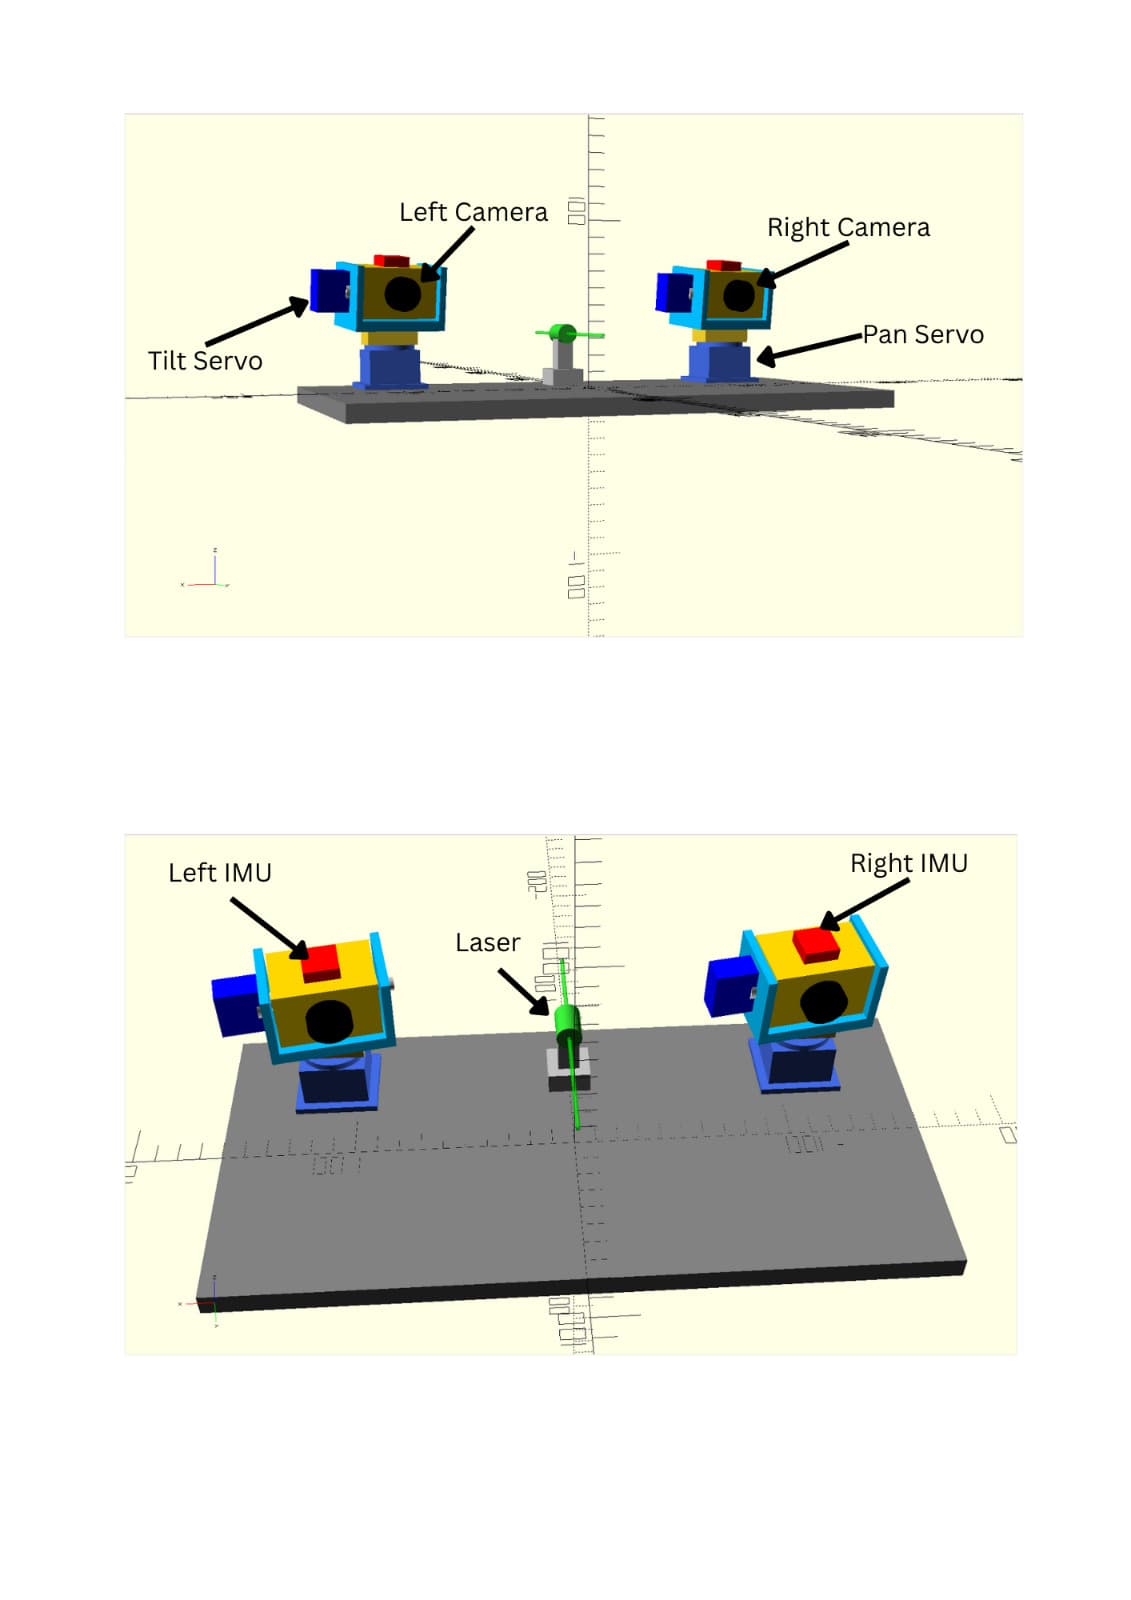
The rig, stereo pair on the pan-tilt mount, as modelled

Recalibration-Free Stereo PTU: Perception hardware

CompletedPatent2025

Published Indian patent application: Self-Calibrating Vision System and Method Thereof, No. 202641064821. Lead inventor.

A stereo pan-tilt unit designed so that the extrinsics stay trustworthy without repeated manual recalibration.

Stereo vision · SGBM · MiDaS · EKF · UKF · IMU

Case study
Details
  • Stereo pair on a pan-tilt mount with IMU reference and a laser anchor for absolute correction.
  • EKF/UKF state estimation fusing SGBM block matching with MiDaS monocular depth priors.
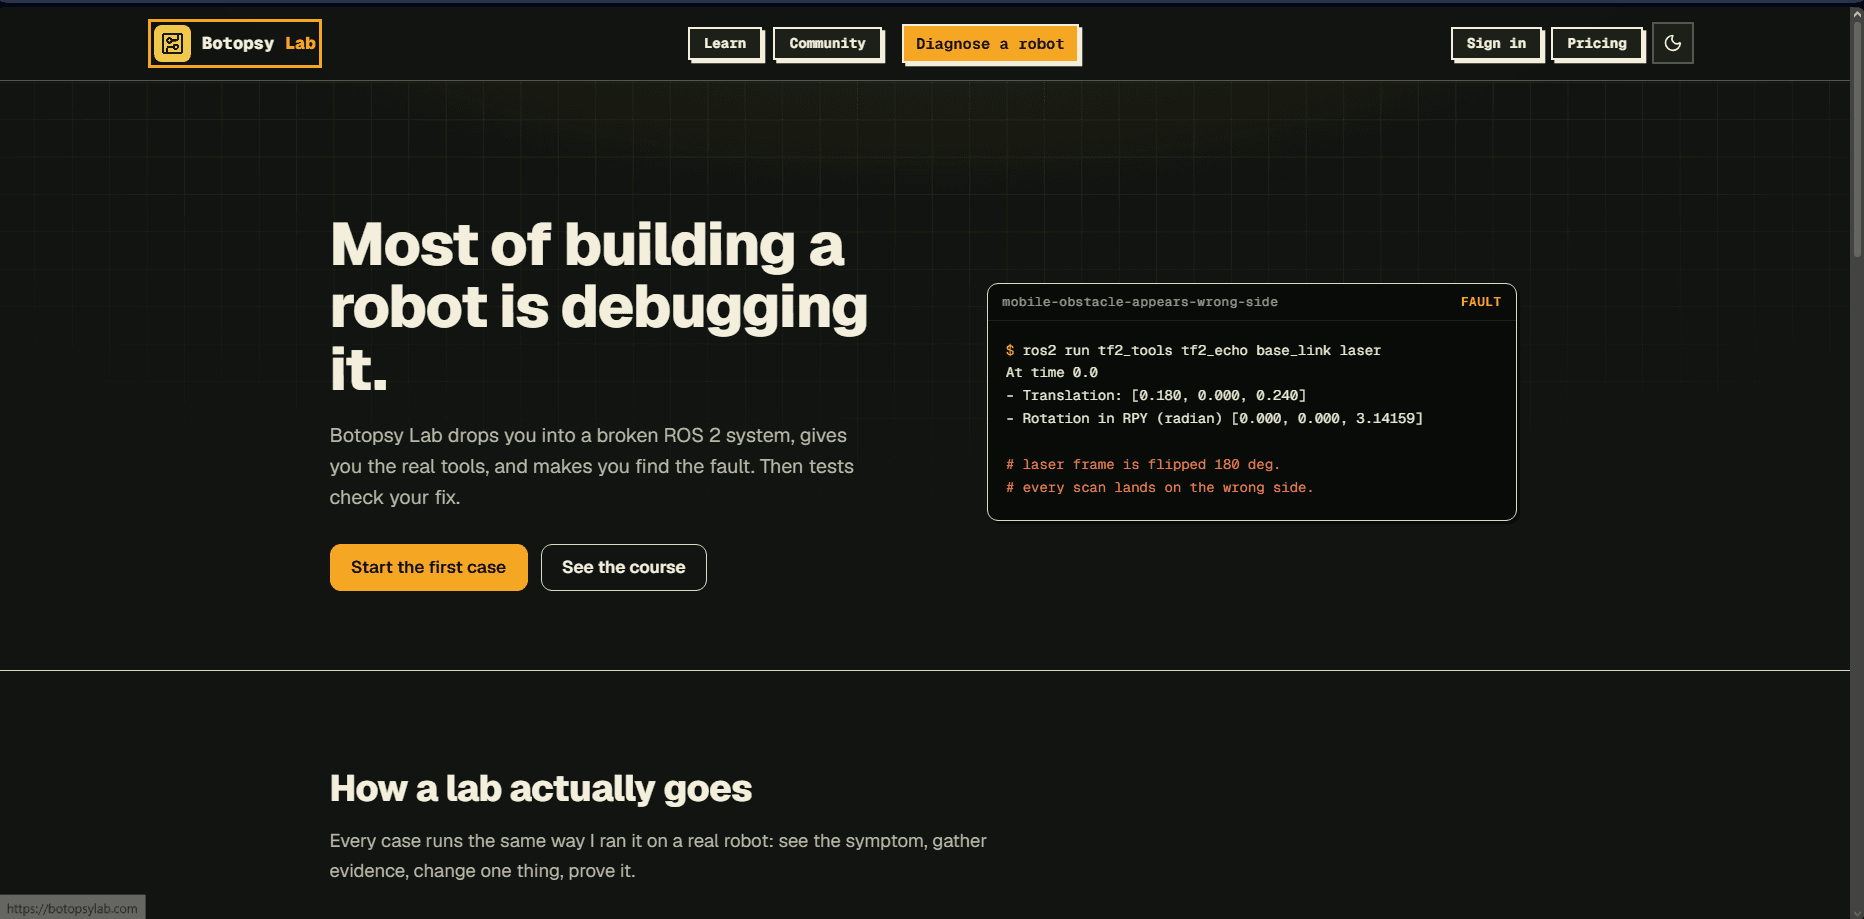
The premise, stated on the front page, a broken ROS 2 system, the real tools, and a test that checks your fix rather than your answer

Botopsy Lab: Robotics education platform

Active development2026

Failure-first robotics education. Students get a broken robot, diagnose it, repair it, and prove the fix, in the browser, with automated grading.

ROS 2 · Browser VMs · Autograding · Curriculum design

Case study botopsylab.com
Details
  • Browser-accessible ROS and ROS 2 environments with VM checkpoints and save/resume.
  • Six courses, 96 graded labs planned; separate teacher-led curriculum for grades 3 to 8.
  • Diagnose → modify → test → prove loop instead of lecture-and-quiz.
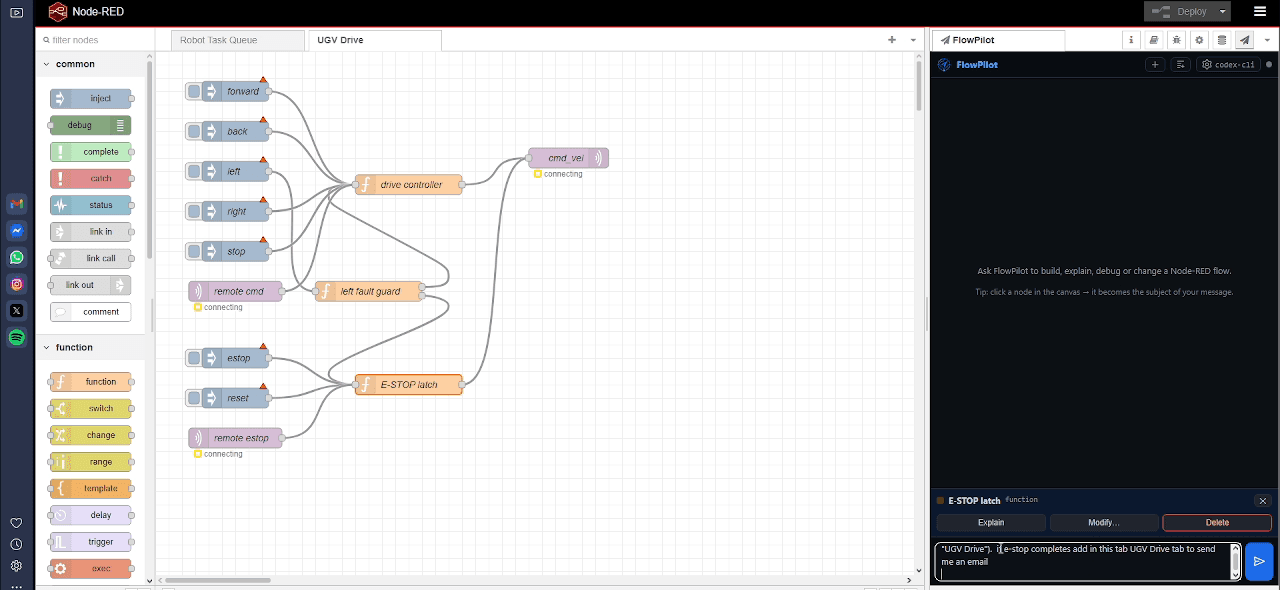
FlowPilot alongside a Node-RED UGV drive flow, drive controller, fault guard and an E-STOP latch selected for explanation

FlowPilot: AI control plane for Node-RED

Active development2026

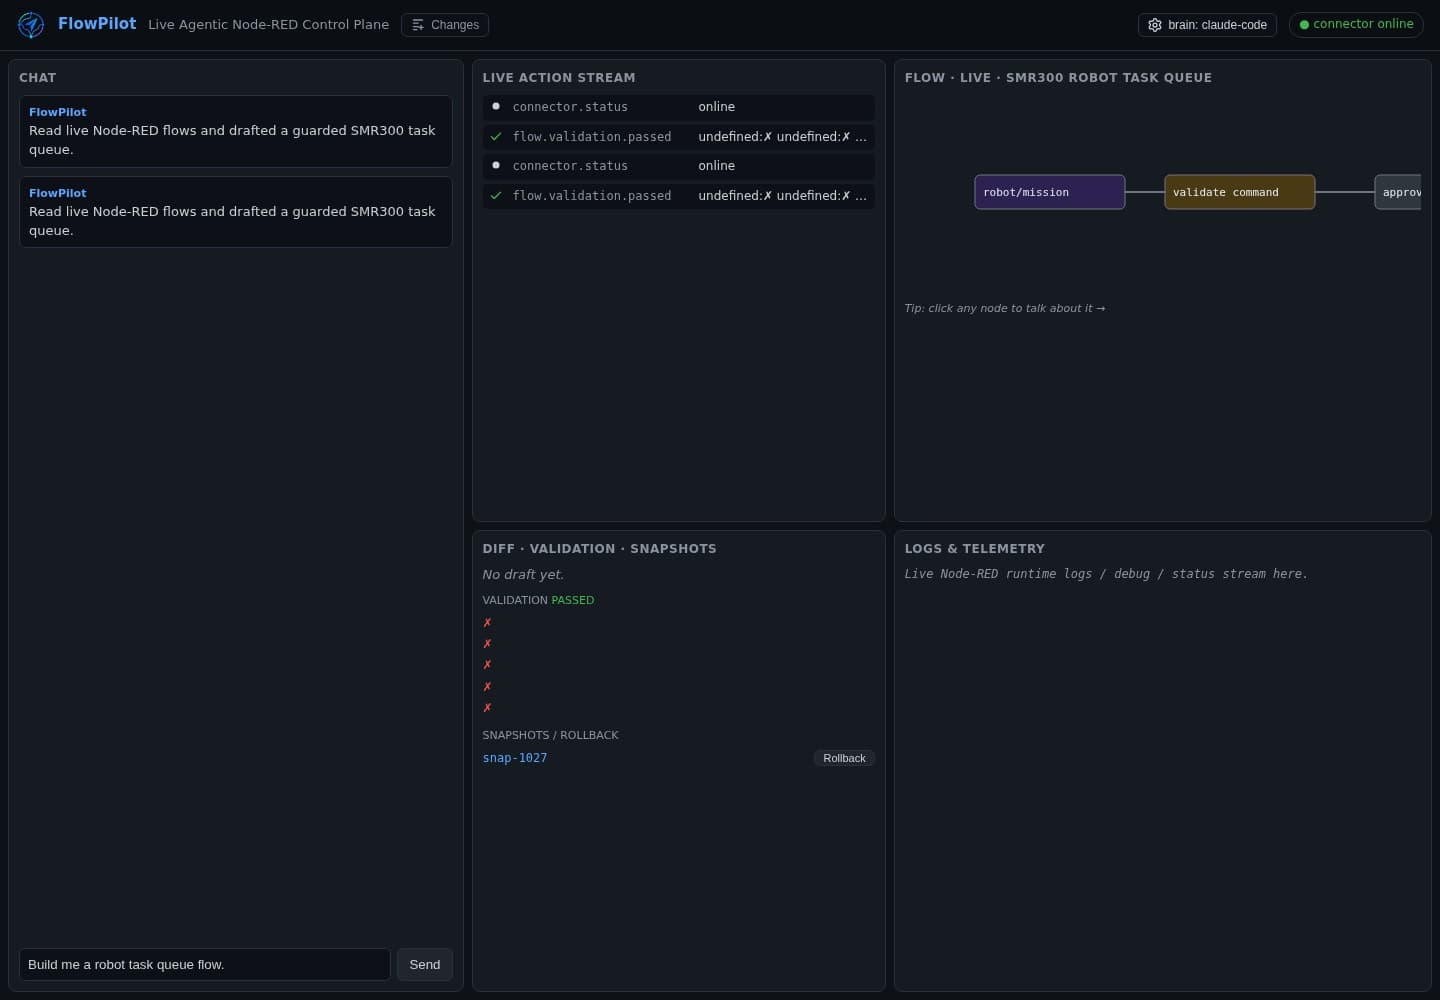
Built out of the Node-RED dashboards I shipped on a factory floor: an AI that drafts flows in plain English but never deploys one that hasn't survived five layers of validation.

React · Vite · Express · WebSocket · SQLite · MCP · Node-RED

Case study Repository
Details
  • Five-layer validation, JSON schema, node catalog, function-code static analysis, security scanning, and sandboxed runtime simulation.
  • Safe deployment with snapshots, approval gates, health checks and automatic rollback on failure.
  • Live monitoring over SSE/WebSocket, plus a role-based permission engine gating tool use by risk level.
  • Outbound-only connector tunnels to Node-RED so the instance is never exposed to the internet.
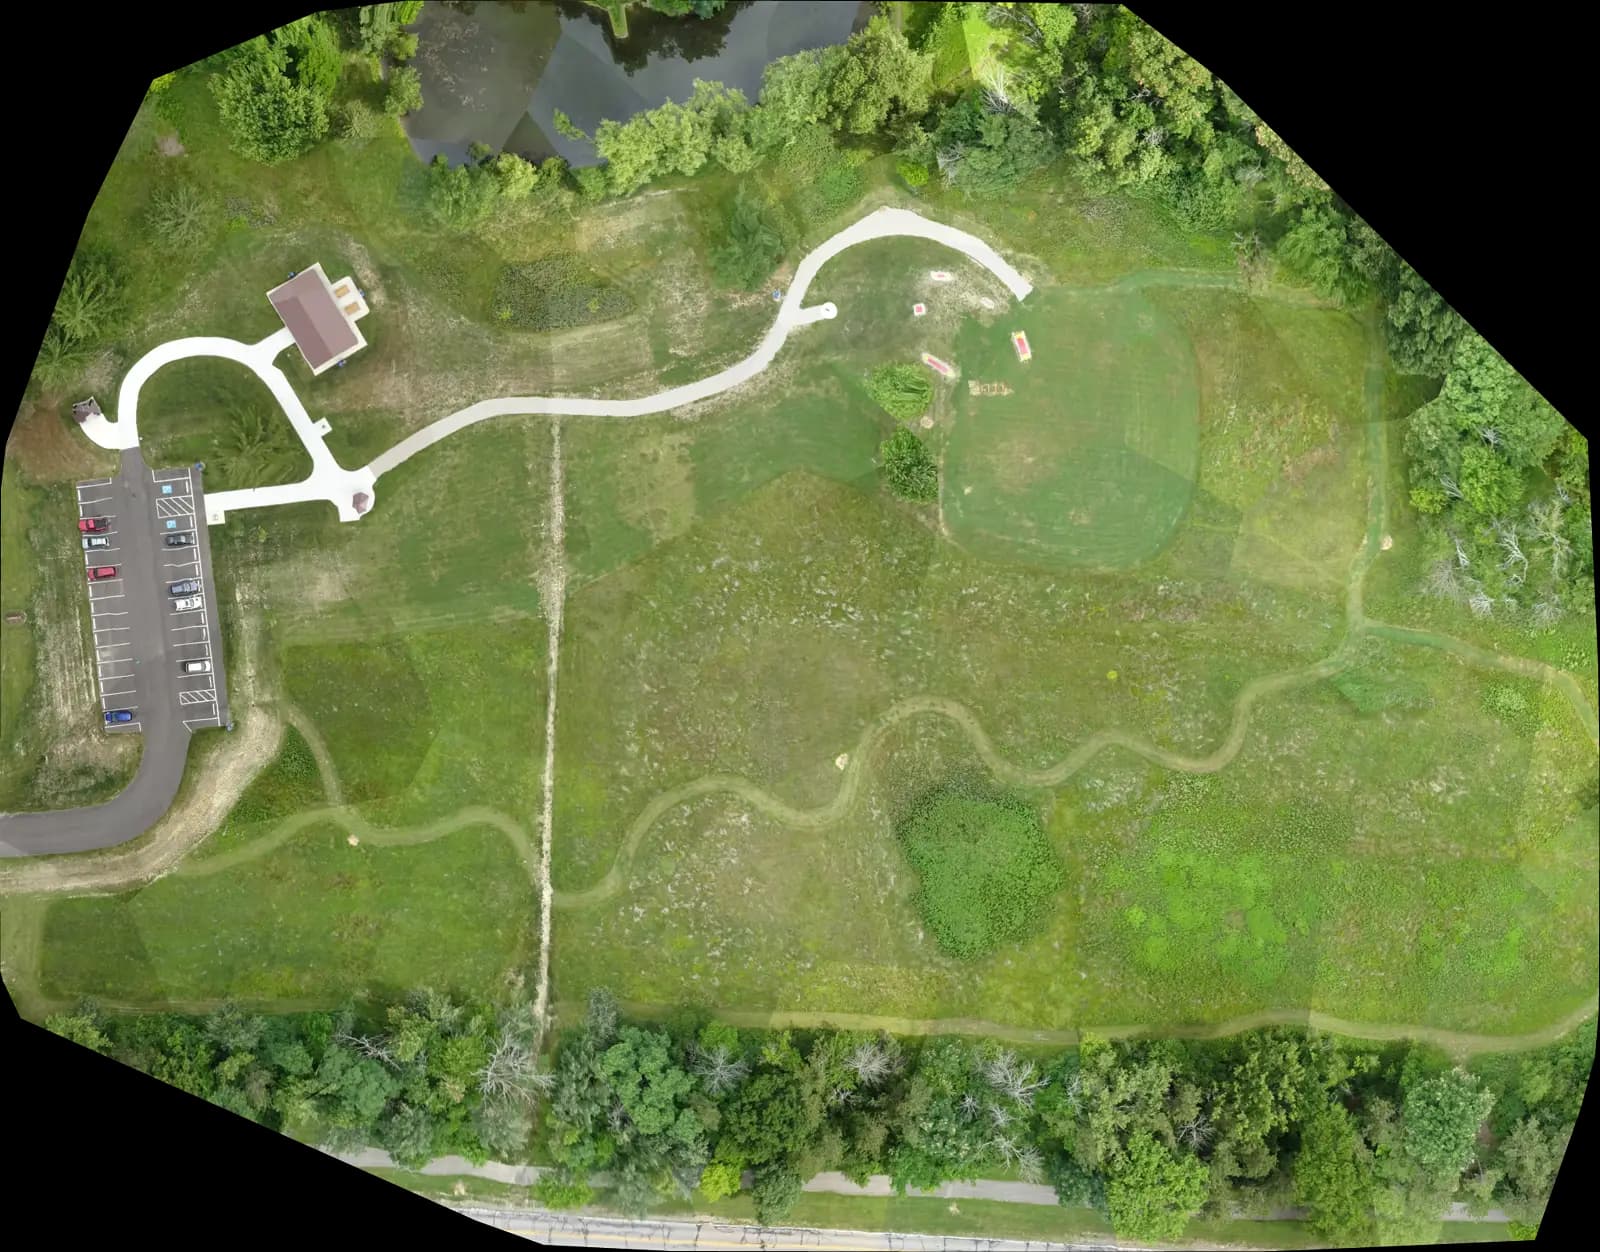
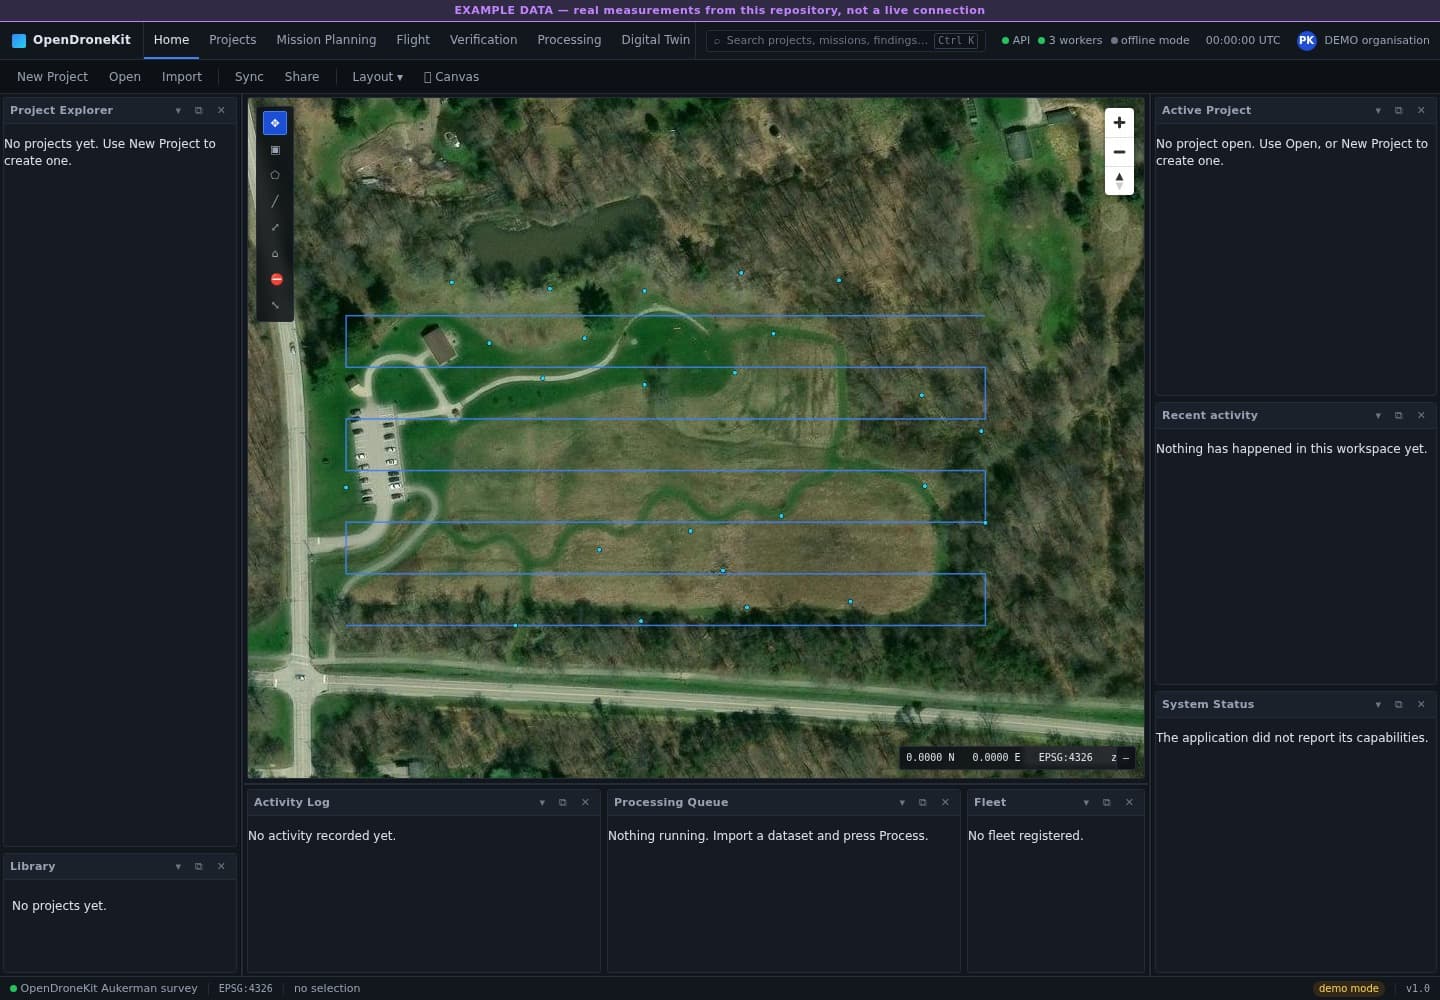
Orthomosaic of the public Aukerman Park survey, 77 photographs at 0.033 m/px, reconstructed offline

OpenDroneKit: Open-source offline drone inspection and GIS toolkit

Active development2025 to present

Survey, inspect and measure, with nothing leaving the laptop. One desktop app plans the mission, flies it over MAVLink, reconstructs georeferenced maps that open in QGIS, marks cracks, corrosion and solar faults for review, measures in metres and writes the client report.

Python · COLMAP · MAVLink / ArduPilot · SegFormer · YOLO11 · PostGIS

Case study opendronekit.com
Details
  • 22 mission templates exported to six autopilot formats, with geofence containment, no-fly detours and terrain following; flight tested against ArduPilot in SITL.
  • COLMAP reconstruction to orthomosaic, DSM, DTM and hillshade: 77 of 77 images registered on the public Aukerman survey, 1.27 px reprojection error, 1.22 m georeference RMSE.
  • Shipped defect models with measured scores, crack segmentation IoU 0.637 and solar cell mAP50 0.88; each finding records the exact weights that produced it, and without a model it declines to guess.
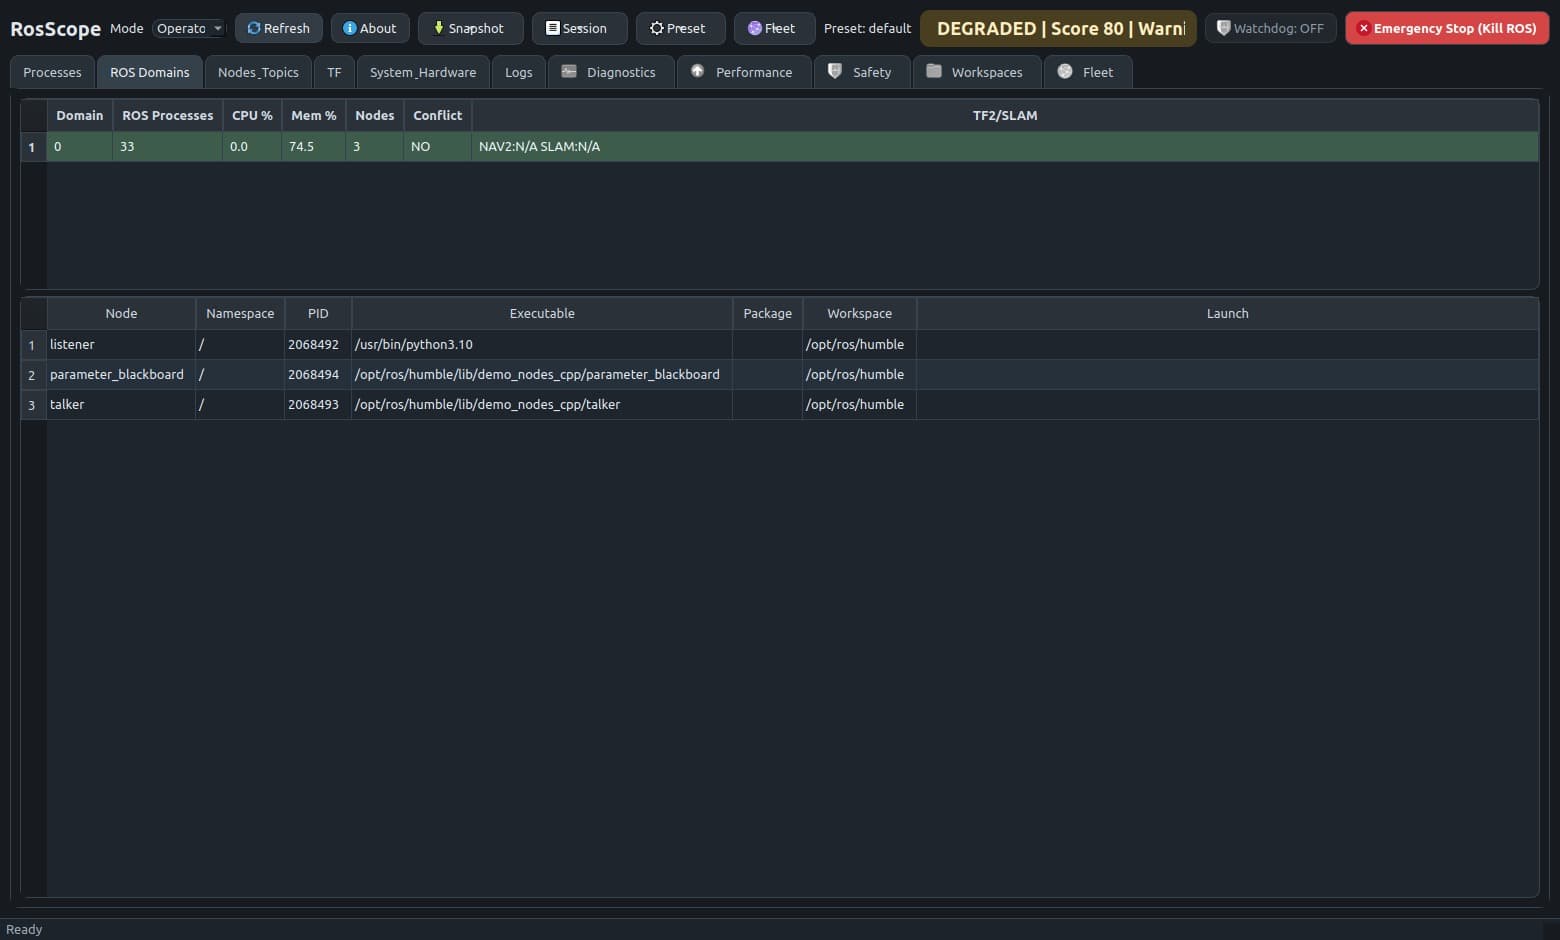
Against a live ROS 2 Humble graph, domain view with process count, conflict state and TF/SLAM status, and every node resolved to its PID, executable and workspace. The health score reads DEGRADED because the graph genuinely is

RosScope: ROS 2 fleet diagnostics

Open source2026

An oscilloscope for ROS 2. A Qt6 desktop tool that shows you what the graph is actually doing instead of making you infer it from scrolling logs.

C++17 · Qt6 · CMake · ROS 2 Humble/Iron/Jazzy · SSH

Case study Repository
Details
  • ROS-aware Linux process monitoring mapped to nodes, domains, PIDs, executables and workspaces.
  • Graph inspection across topics, QoS, TF, Nav2 and lifecycle state, with zombie-process, conflict and missing-link detection.
  • Process control, snapshot export, session recording, and SSH-based remote fleet monitoring.
  • Dual UI: an engineer mode for diagnostics and a stripped operator mode for the floor.
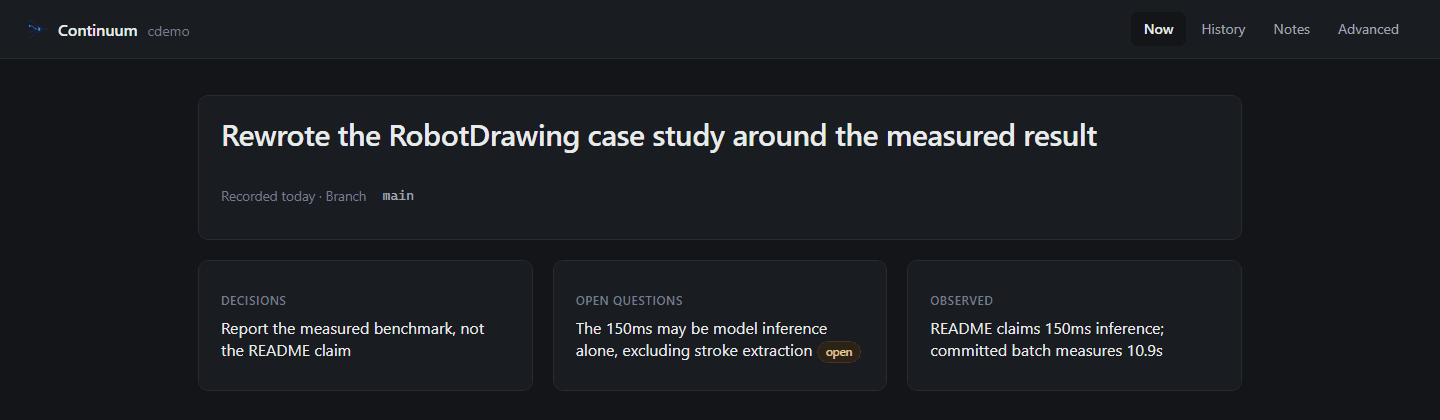
The Now view, current task, decisions taken, and open questions carried between agent sessions

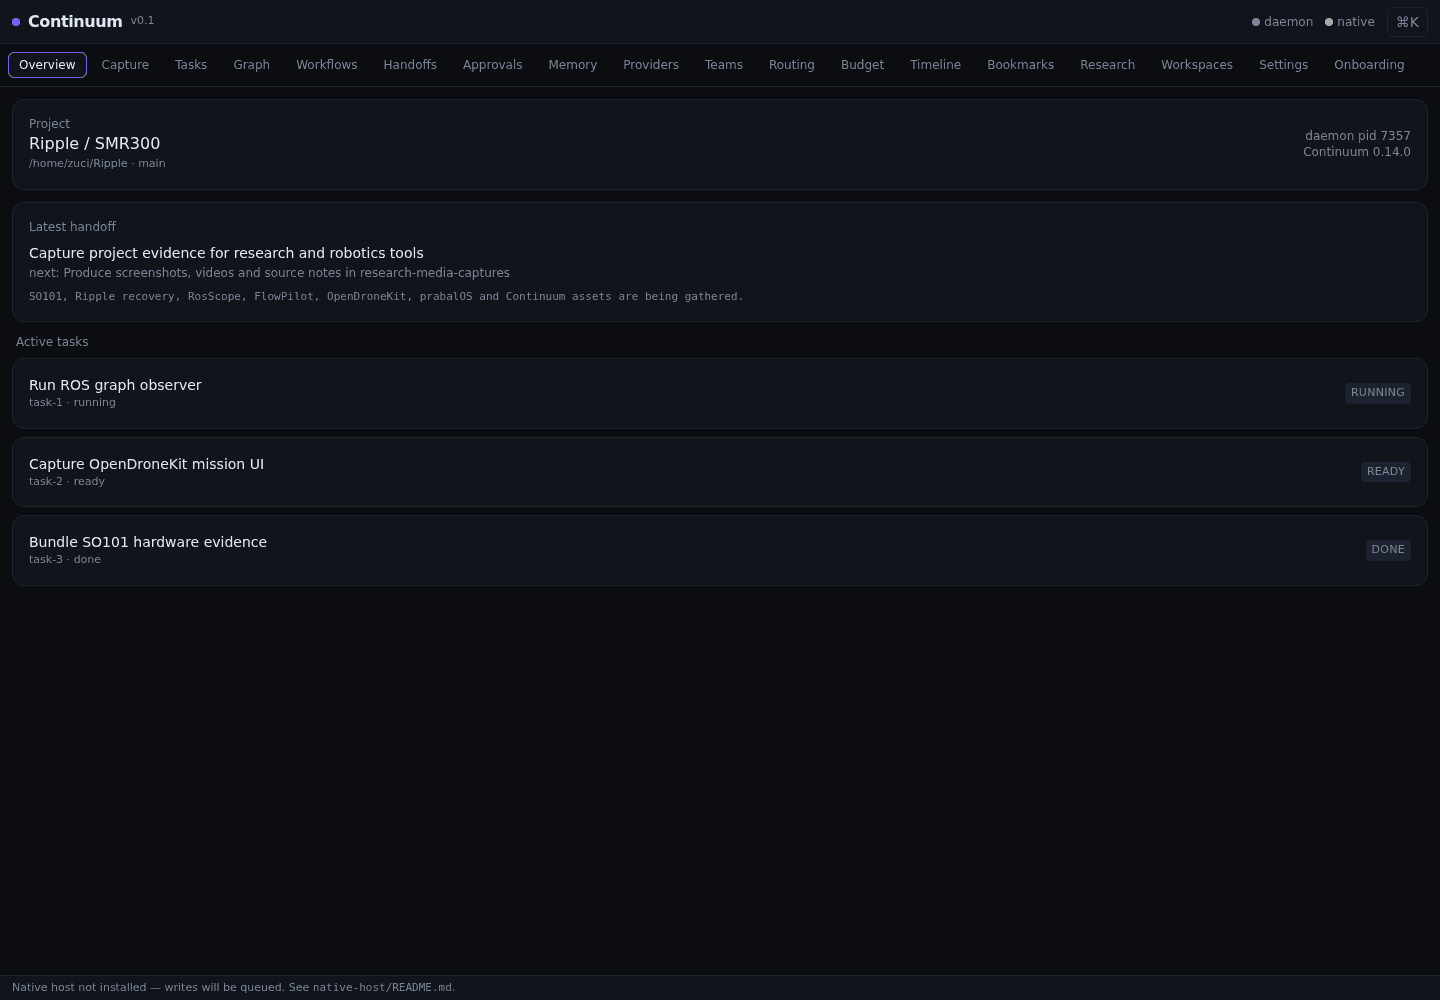
Continuum: Open-source AI agent memory

Open source2026

Git, but for the context your AI agent is holding. Switch from Claude Code to Codex to Gemini without re-explaining the codebase, the bug, or what you already tried.

Python · SQLite · MCP · Agent hooks · CLI

Case study Repository
Details
  • Three-layer architecture mirroring Git: an append-only SQLite event log, checkpoints as commits, and a materialized `current.md` view.
  • `continuum log / diff / blame / restore / branch / merge`, plus `note`, `ask`, and semantic `search` over recorded decisions and hypotheses.
  • Local-first: everything lives in `.continuum/`, nothing uploads by default. Ships as a Claude Code plugin and an MCP server.
  • Repo benchmark reports 100% recall accuracy with context injection versus 17 to 20% without, ~94% context compression, and agent response time dropping from 17 to 21 s to 5.5 s.

Other fun projects

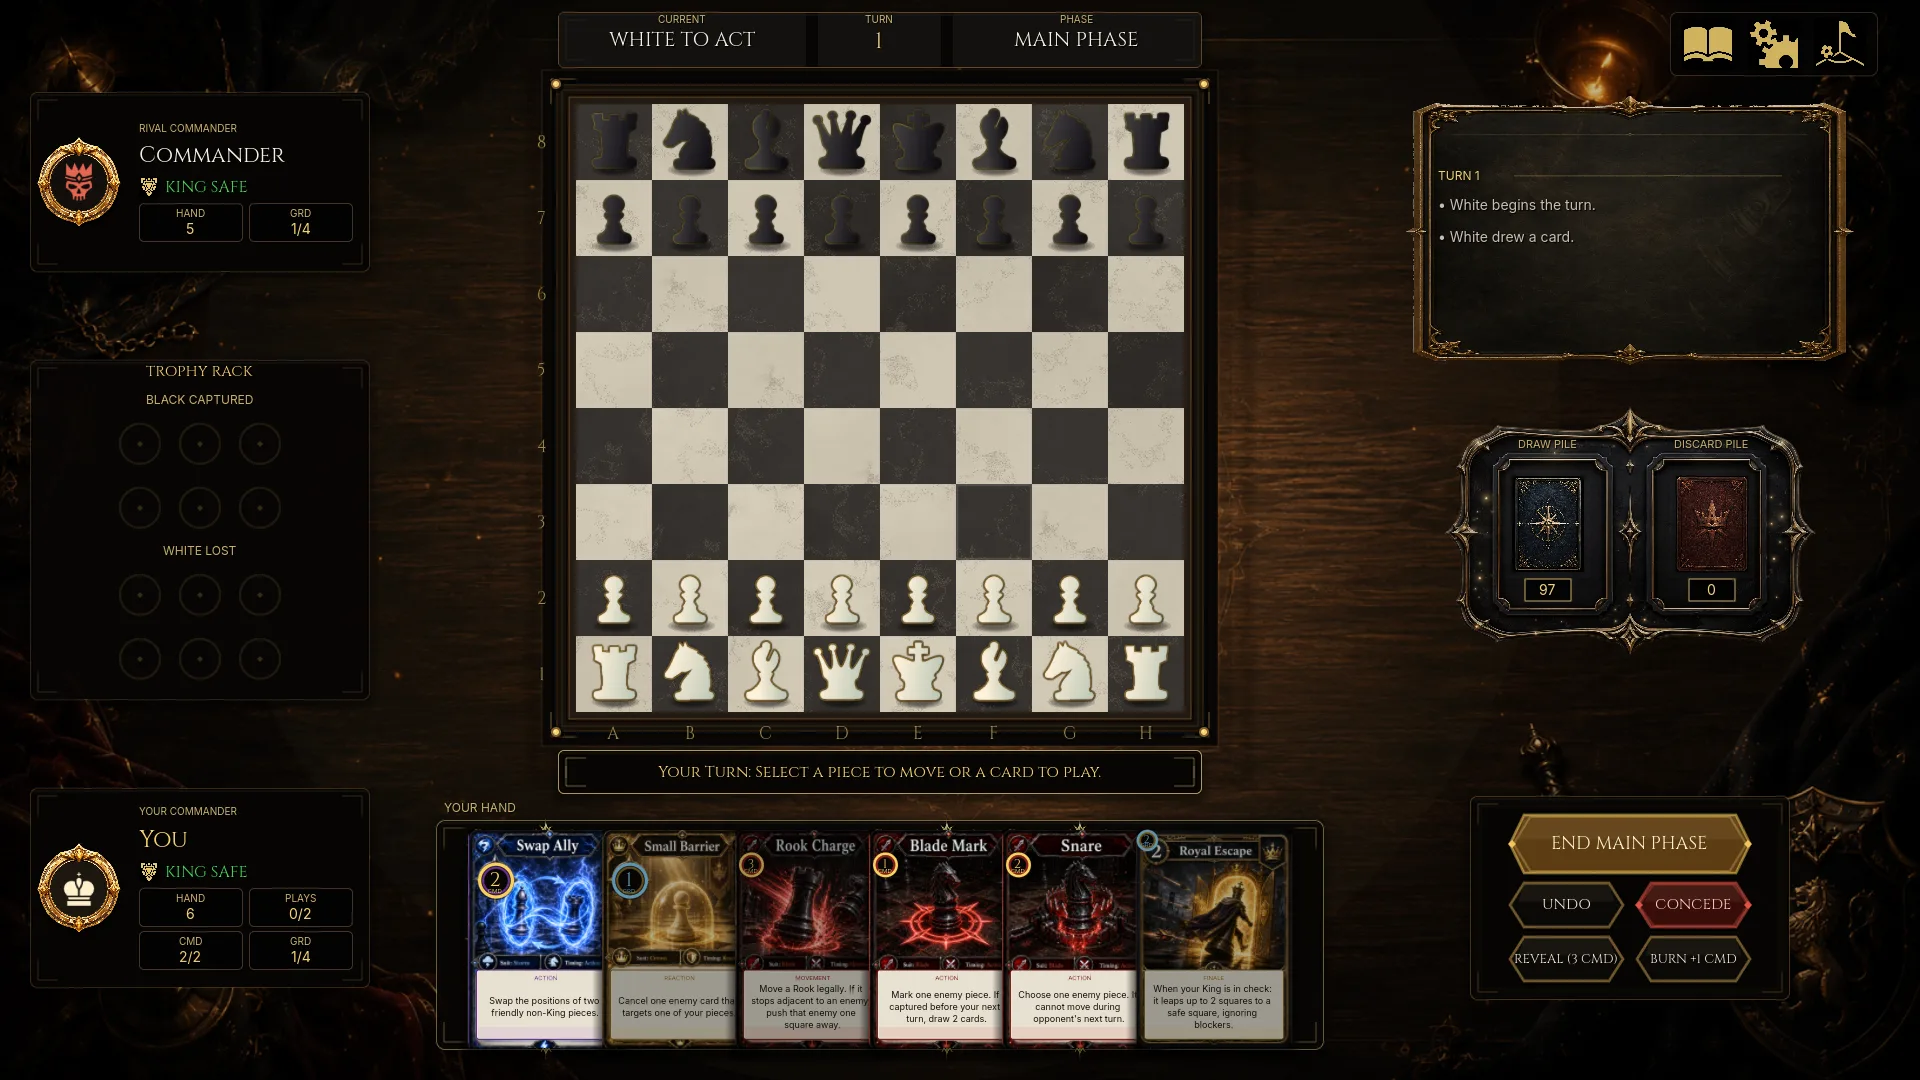
A game in progress: the chess board with the card hand

CrownFall: Chess collapses into chaos: a chess and card strategy game

Active development2026

A free strategy game that combines chess with card play, for Windows and Mac with online cross-play. 64 cards across four suits, reactions that can cancel a card, rewind a capture or escape checkmate, four bot opponents up to Grandmaster, 50 hand-built puzzles and online play with room codes. In free beta.

Windows · macOS · Online cross-play · Game design

FaceTrack: Vision to actuation in the shortest possible loop

Completed2023

Webcam frames through OpenCV face detection, forehead coordinates computed and sent over serial to an Arduino driving two servos. Deliberately the smallest complete perception-to-actuation loop.

Python · OpenCV · Arduino

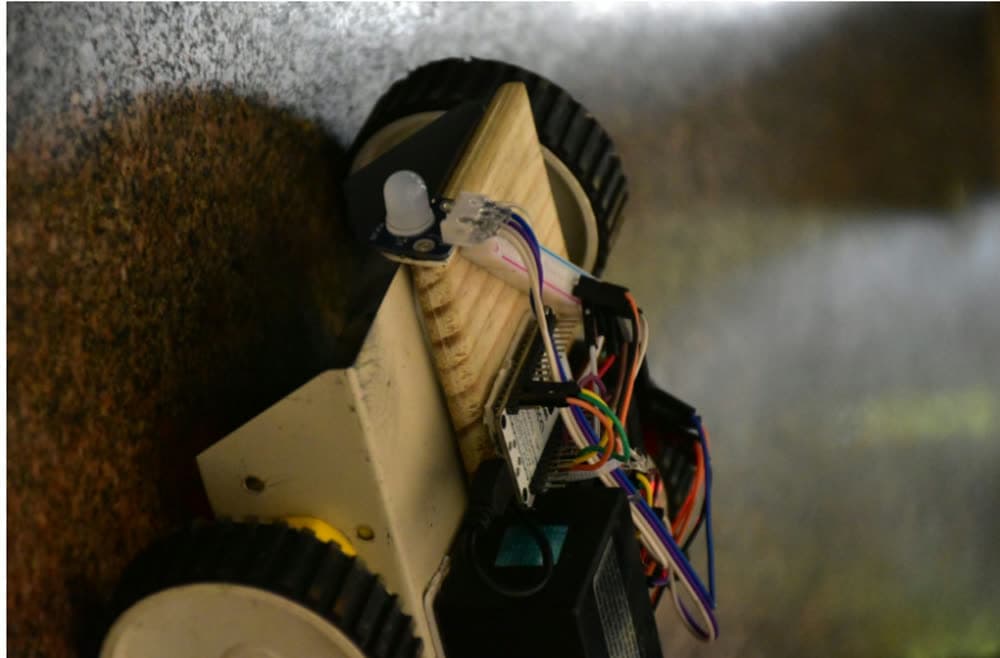
The glove and the car, an IMU on the back of the hand, the receiver on the chassis

Gesture-Controlled Car: An IMU glove commanding a car over ESP-NOW

Completed2023

Gesture data from an IMU glove transmitted as binary over ESP-NOW, received by an ESP device and passed to an Arduino over serial for motor control.

C++ · ESP-NOW · Arduino · IMU

Also built

  • next_EKF · 2026

    Odometry and IMU fusion, tuned from measured noise

    ROS 2 Humble · robot_localization · Allan variance · EKF · C++

    Case study →Repository ↗
  • next_HI · 2026

    CANopen hardware interface and the CiA 402 state machine

    ros2_control · CANopen · CiA 402 · SocketCAN · SLAM Toolbox

    Case study →Repository ↗
  • Continuum Extension · 2026

    Browser capture surface for agent context

    React · Vite · Tailwind · MV3 · Native messaging

    Case study →Repository ↗
  • InfrenceX CLI · 2026

    Agentic terminal over a decentralized model market

    Node.js · Ink · TypeScript · JSON-RPC · MCP

    Case study →Repository ↗
  • ContractEncrypt · 2025

    Lattice and ECC encryption under simulated quantum attack

    Python · NumPy · PyCryptodome · Qiskit · LWE

    Case study →Repository ↗
  • smr300l_gazebo_ros2control · 2026

    The SMR300 in simulation, so changes could be tested off the floor

    Gazebo · ros2_control · ROS 2

    Case study →Repository ↗
  • claude-skills · 2026

    Reusable agent skills, packaged

    Shell · Agent skills

    Case study →Repository ↗

Experience

Robotics Software Intern · Next Robotics Lab Co., Ltd.

Jan 2026, Jul 2026

Pathum Thani, Thailand

  • Architected a reusable ROS 2 autonomy stack for the 300 kg SMR300 AMR, integrating LiDAR, PGV, Nav2, an AI camera, CANopen and CiA 402, replacing the company's prior ROS 1 architecture.
  • Validated navigation across 150 shelf-docking trials and 150 point-to-point runs: 97% docking success, 2 cm shelf docking error, point-to-point mismatch cut from 5 cm to a 3 cm mean.
  • Implemented reflective-marker recognition for two- and four-legged shelves using LiDAR clustering, center checks, automatic repositioning, sector safety gating, safe aborts and alerts; root-caused failures traced to sunlight reflections at open factory doors.
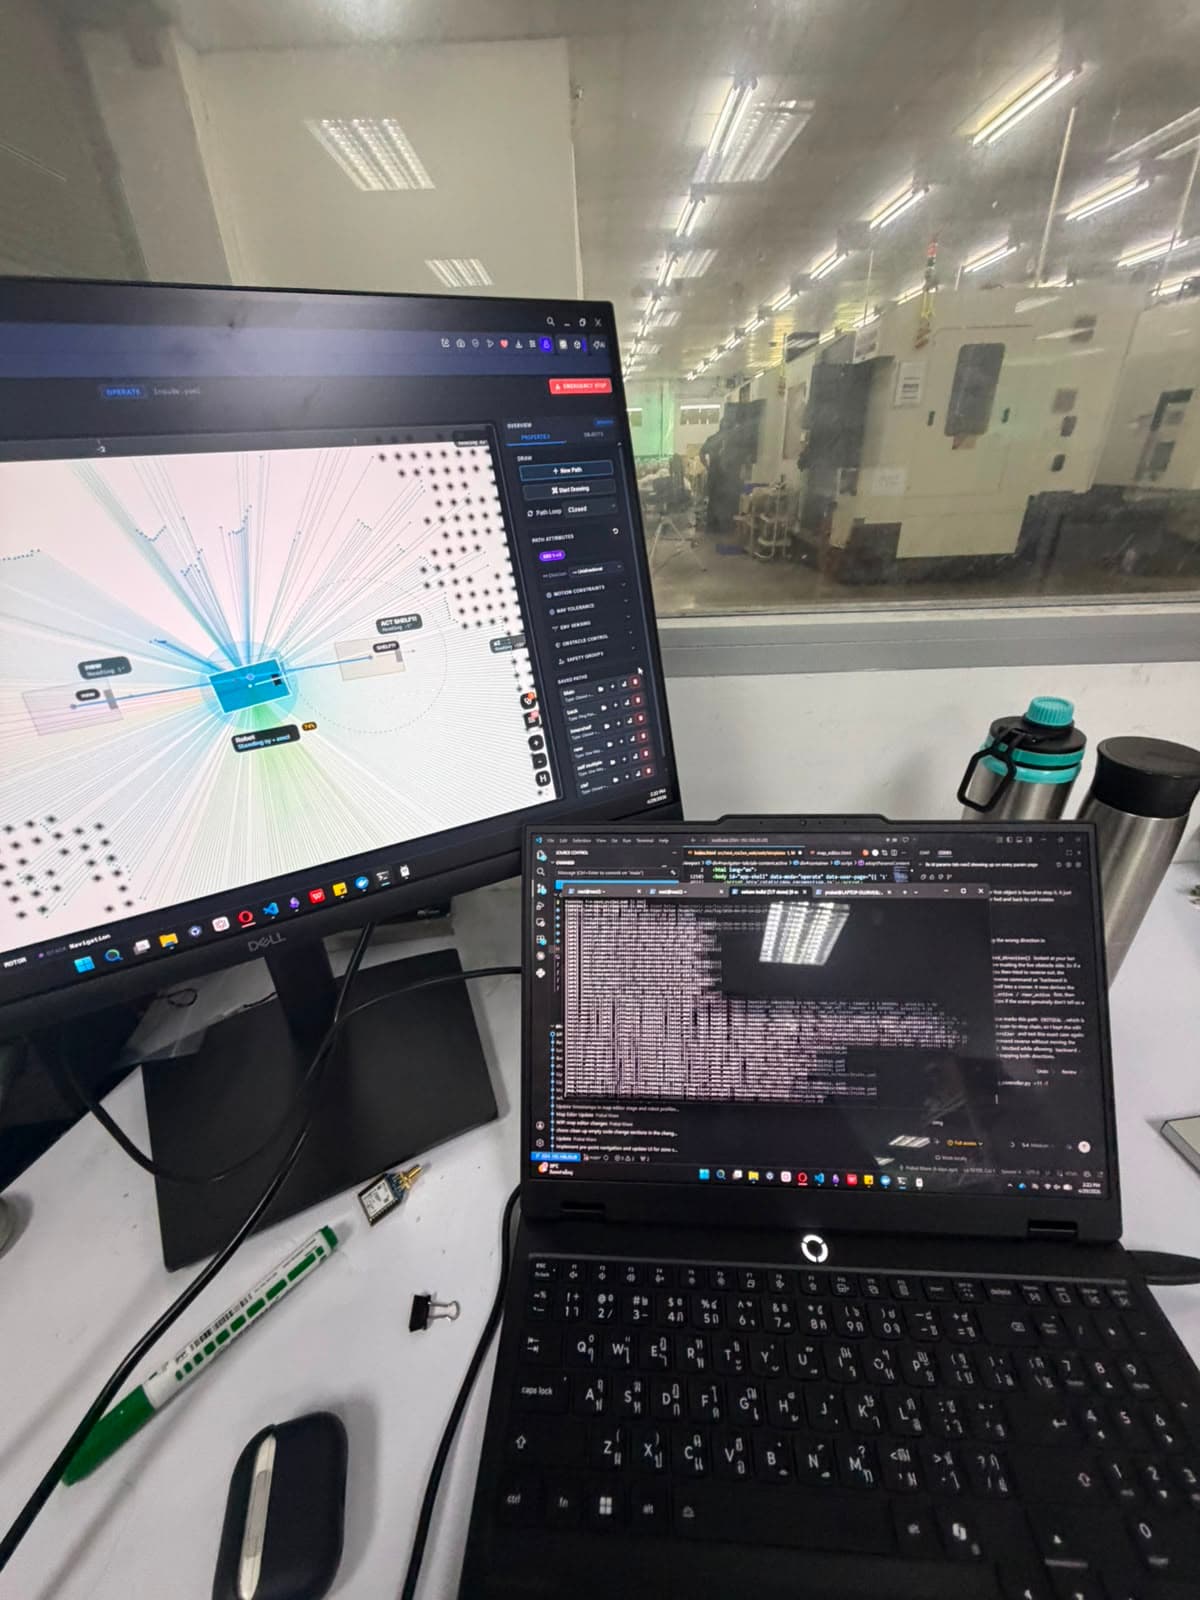
  • Built an operator platform for mapping, map editing, URDF and sensor configuration, Nav2 parameter tuning, mission control, monitoring and deployment validation, plus a Node-RED dashboard evaluated by 5 operators and 2 engineers.
  • Developed Python, C++, JavaScript and Web API components for path following, zone management, map handling, robot profiles, workflow management and robot bringup.

ROS 2 Humble · Nav2 · CANopen · CiA 402 · PGV · LiDAR · C++

Repository ↗

Hardware Engineering Intern · Theta Sound

Jan 2025, Oct 2025

Remote

  • Researched smart-earphone architectures and produced multiple PCB layouts and simulated prototypes, evaluating Qualcomm audio platforms, ANC, Bluetooth, microphones, battery systems, PPG and IMU health sensing, and sensor fusion.
  • Modeled board footprint, battery life and power consumption to guide an early prototype for engineers and manufacturers; led a KiCad PCB design workshop for 50 attendees.

KiCad · PCB · ANC · PPG · IMU · Power budgeting

AI Software Development Intern · Drone Entry

Jun 2025, Aug 2025

Thailand

  • Built OpenDroneKit, a PyQt6 structural-inspection workflow spanning ~40,000 metal, brick and other defect images, integrating YOLOv8 detection and U-Net crack segmentation.
  • Mapped detected cracks onto COLMAP 3D reconstructions and connected segmentation masks to FEniCSx simulations to estimate crack propagation over time and flag structural severity.
  • Implemented desktop workflows for project setup, dataset import, defect analysis, reconstruction and report generation.

PyQt6 · YOLOv8 · U-Net · COLMAP · FEniCSx

Repository ↗

R&D Summer Intern, Robotics & Drones · Drone Academy

May 2025, Jun 2025

Thailand

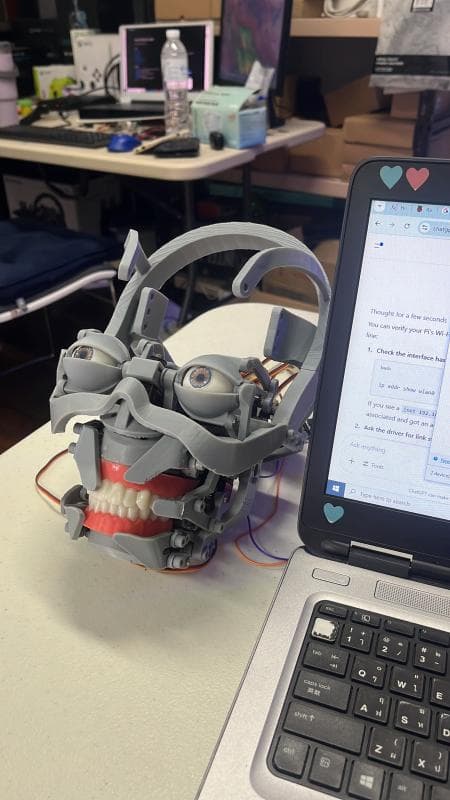
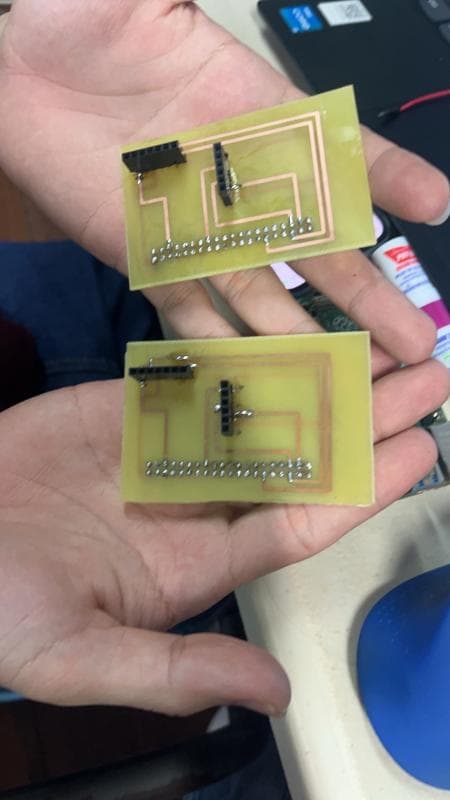
  • Designed and fabricated 3 PCBs, an animatronic head, Raspberry Pi 4 I/O, and an RC car kit, driving eye, jaw and head servos plus a speaker through GPIO.
  • Ran text-to-speech and a 2B-parameter language model locally on an 8 GB Raspberry Pi 4; validated the RC car board for sale as a build-your-own educational product.

PCB · Raspberry Pi 4 · Animatronics · Local LLM · TTS

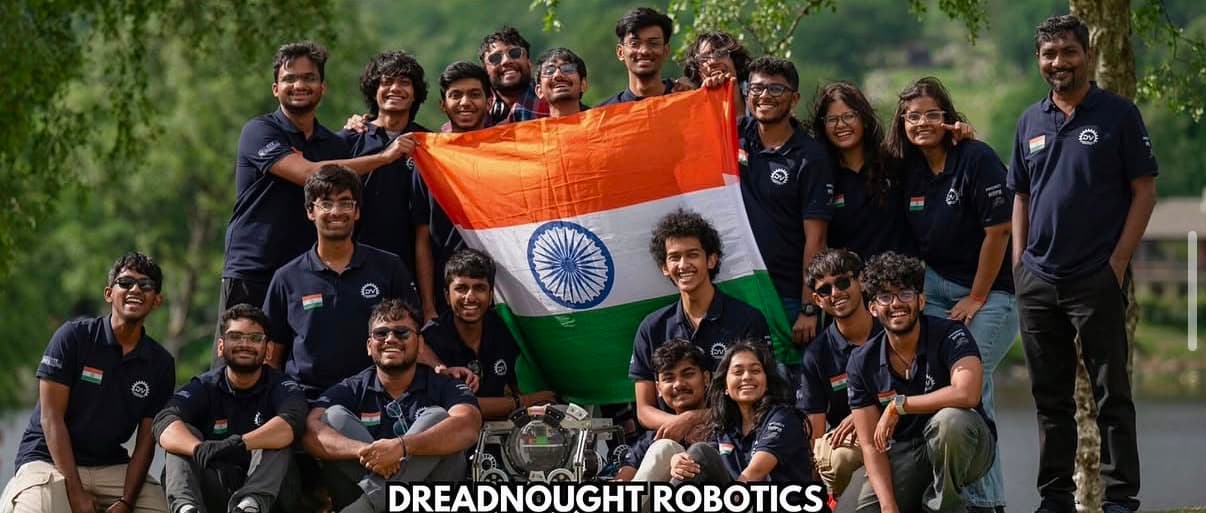
Resource Head · Systems Department · Dreadnought Robotics

Aug 2023, Jun 2025

Chennai, India

  • Managed a $15K+ budget, inventory and procurement for 120 members across 4 departments, comparing alternatives on cost, availability and system fit.
  • For Project MIRA, designed electrical systems for reliable operation inside a sealed AUV pressure hull and developed ROS, MAVROS and MAVLink control software, contributing to 2nd place at TAC Challenge Norway 2024.
  • Integrated power distribution, hydrophones and sensor-control subsystems while coordinating cross-functional testing across hardware and software teams.

ROS · MAVROS · MAVLink · AUV · Power distribution

Patents

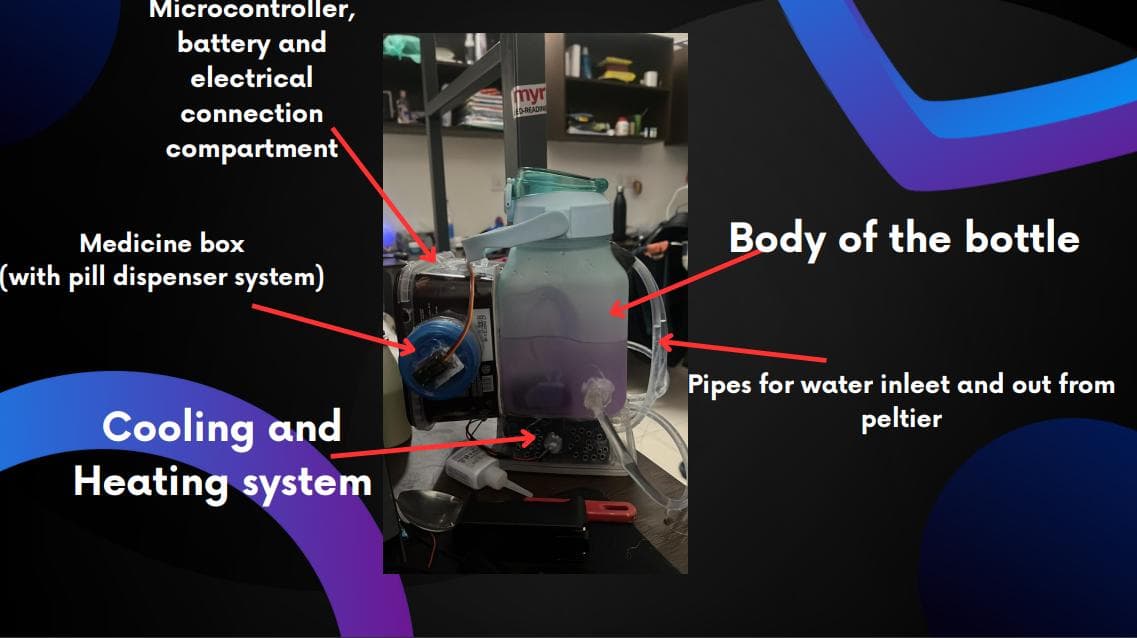
Prototype bottle: Peltier loop, sealed electronics bay, pill dispenser

Container for Dispensing Medications

Published, awaiting examination · 202641121625 · 16 October 2026

A smart bottle that carries medication and the water to take it with. A Peltier stack under the body heats or cools the contents through inlet and outlet lines, a sealed compartment holds the microcontroller, battery and wiring, and an integrated dispenser on the side releases the pills.

Pill dispenser · Peltier · Thermal design · BMS · Embedded

Kurat, RealSense D435i and Jetson Orin Nano on a four-wheel chassis

A System for a Companion Robot

Published · 202641114580 · 2 October 2026

The system behind Kurat: a companion robot built on a three-brain architecture that separates perception, cognition and action, so each layer can fail and recover without taking the others down. Perception, speech, localization and navigation run on board a Jetson Orin Nano with a RealSense depth camera.

Companion robot · Three-brain architecture · Jetson Orin Nano · RealSense · ROS 2

The stereo pan-tilt rig: stereo pair, IMU reference and laser anchor

Self-Calibrating Vision System and Method Thereof

Published · 202641064821 · 2026

A stereo pan-tilt vision system whose extrinsics stay trustworthy without repeated manual recalibration. An IMU reference and a laser anchor correct drift, and an EKF/UKF fuses SGBM block matching with monocular depth priors.

Stereo vision · Self-calibration · IMU · EKF / UKF · SGBM

The drone-rover in flight mode, arms deployed

AI-Enabled Search-and-Rescue Robot

Published · 202641035669 · 2026

One vehicle that drives and flies. Four arms carry both the propellers and geared drive wheels, so it rolls through terrain on the ground and lifts off when the ground runs out, with AI-driven visual and thermal detection for search and rescue in GPS-denied environments.

UAV-UGV · Search & rescue · GPS-denied · Thermal · Raspberry Pi

Media

SMR300

Autonomous shelf docking, approach, align, lift
SMR300 on the factory floor, squaring up to a shelf
Operator control plane, live scan, path editor, safety groups
PGV mode, tag-referenced localization run
FlowPilot / Node-RED, guarded robot task queue flow
RosScope live graph, talker, listener, parameter_blackboard
RosScope / SMR300 demo footage

SO101

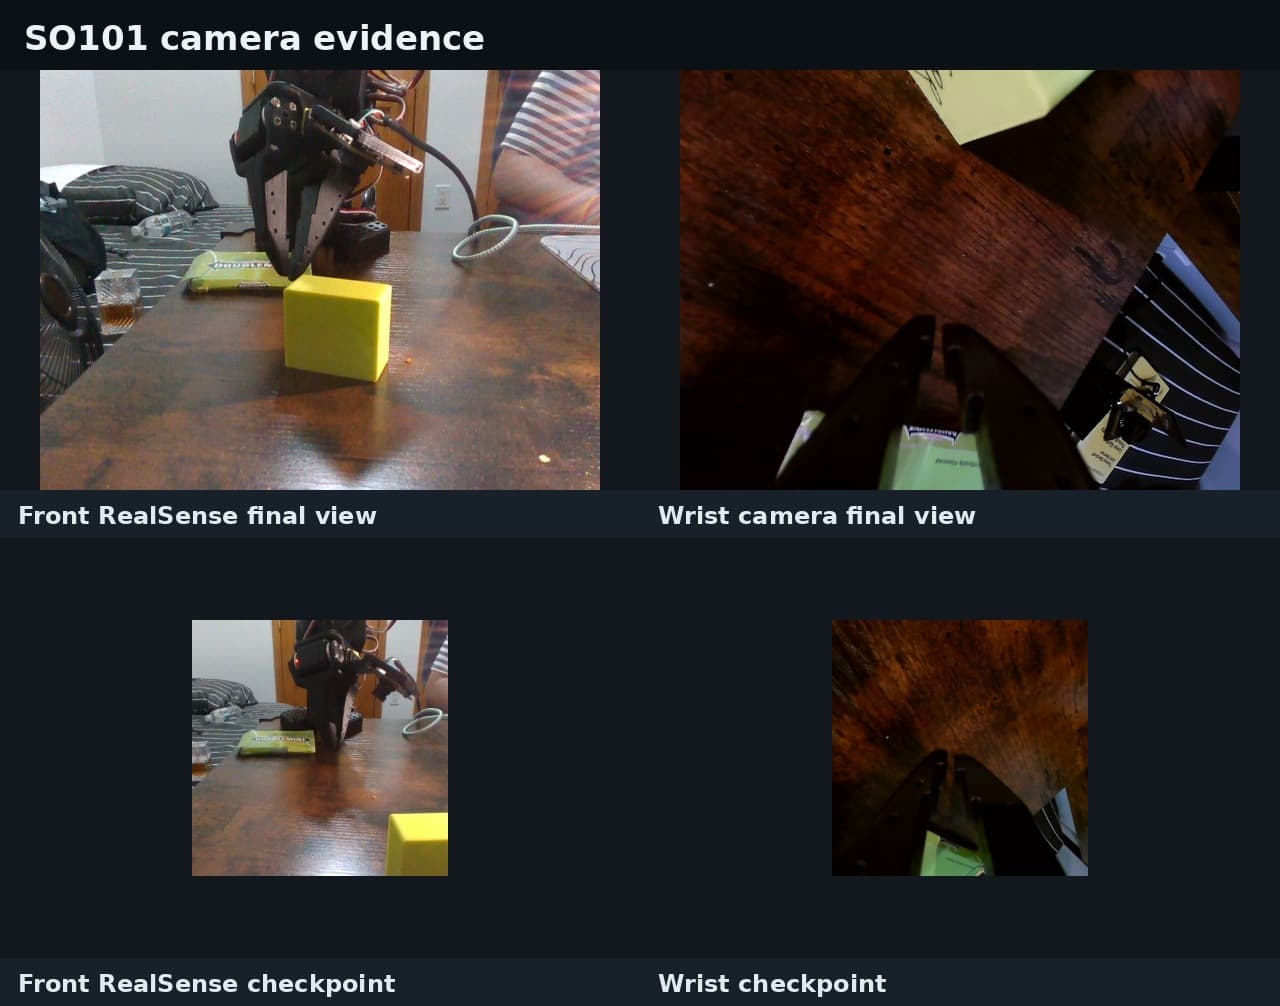
SO101 camera evidence, front RealSense and wrist views
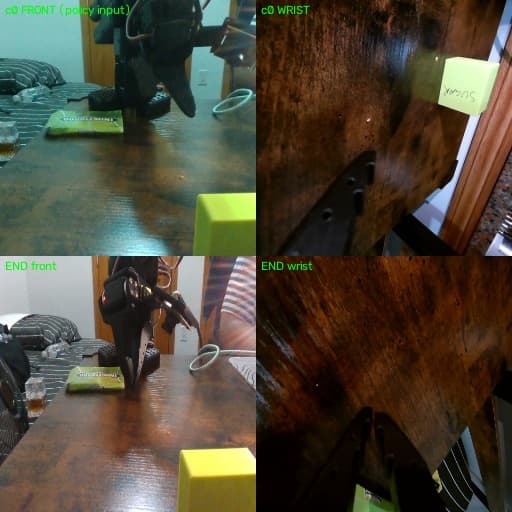
SO101 hardware evidence from the real-arm setup
SO101 real-arm rollout
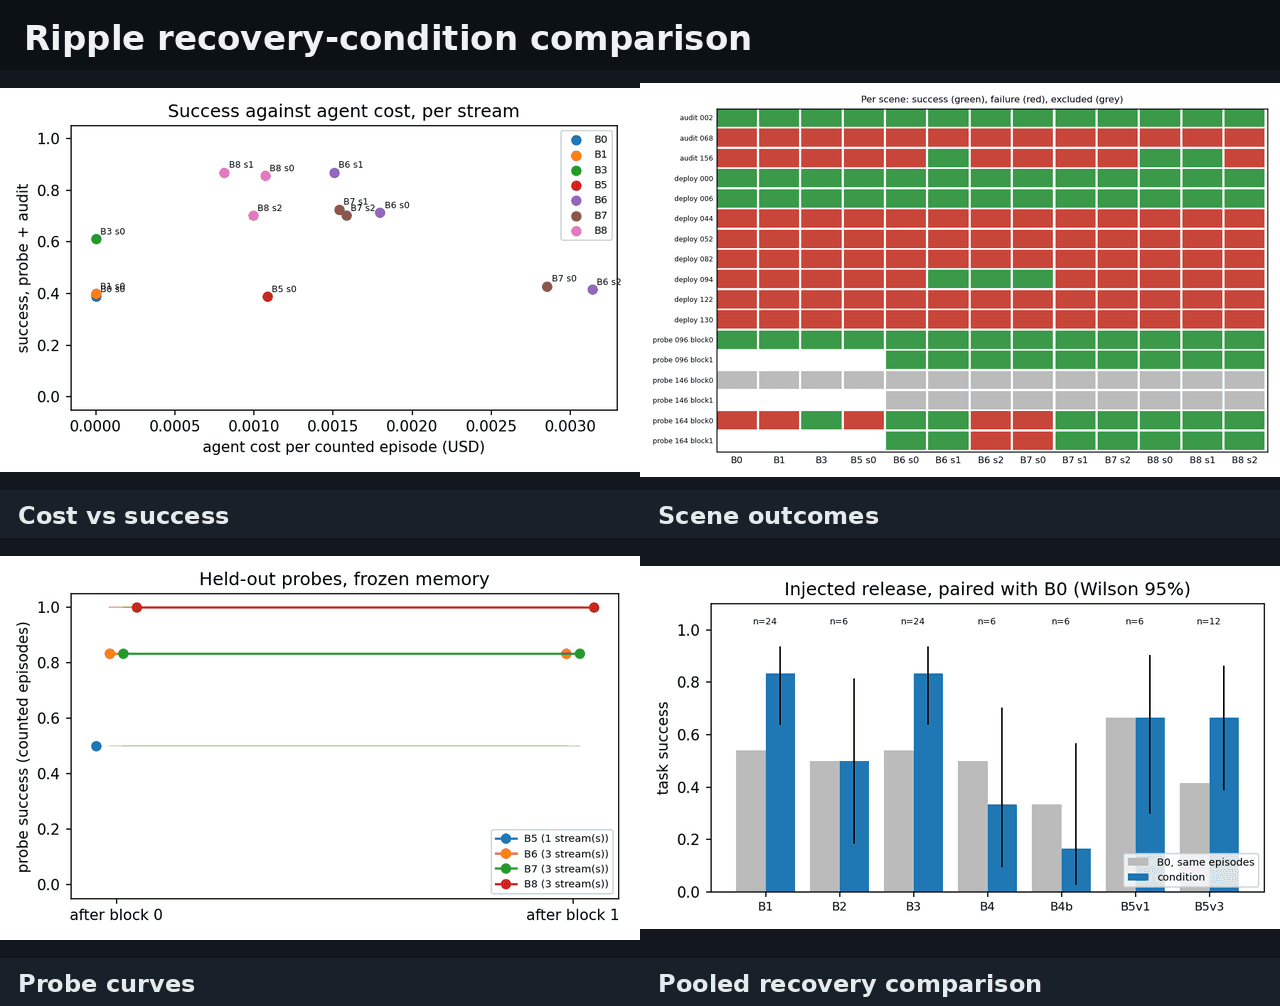
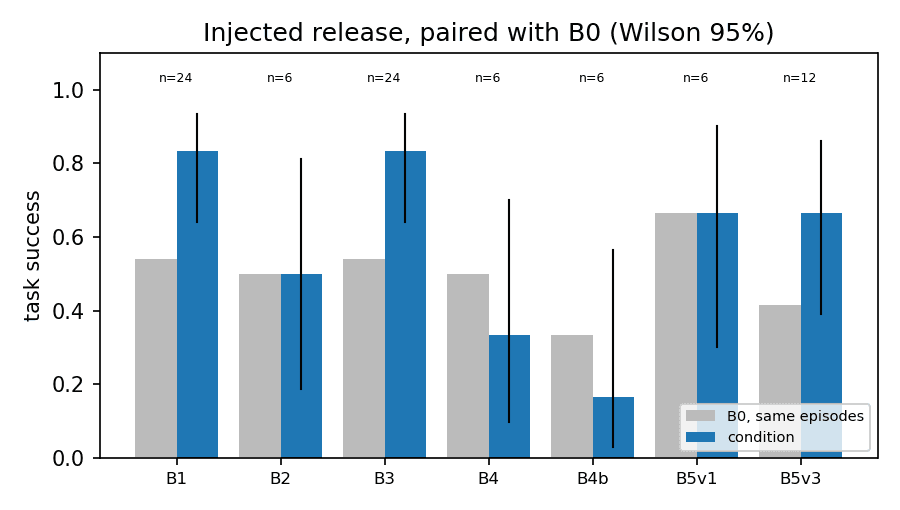
Ripple recovery-condition comparison: cost, scene outcomes, probes, pooled results
Ripple injected pooled recovery result

Project MIRA

Project MIRA, extruded aluminium frame, ducted thrusters, domed pressure housings
Second place, TAC Challenge Norway 2024, Dreadnought Robotics
Project MIRA, autonomous docking run
MIRA under test

Patents

Transformation Drone, rover mode, driving on geared hubs
Transformation Drone, flight mode, arms deployed
Thermoregulating bottle, Peltier loop, sealed electronics bay, pill dispenser
Transformation Drone, driving and flying on the same four arms

UAV

VTOL search-and-rescue quadplane, plank wing, four lift rotors, exposed avionics

Kurat

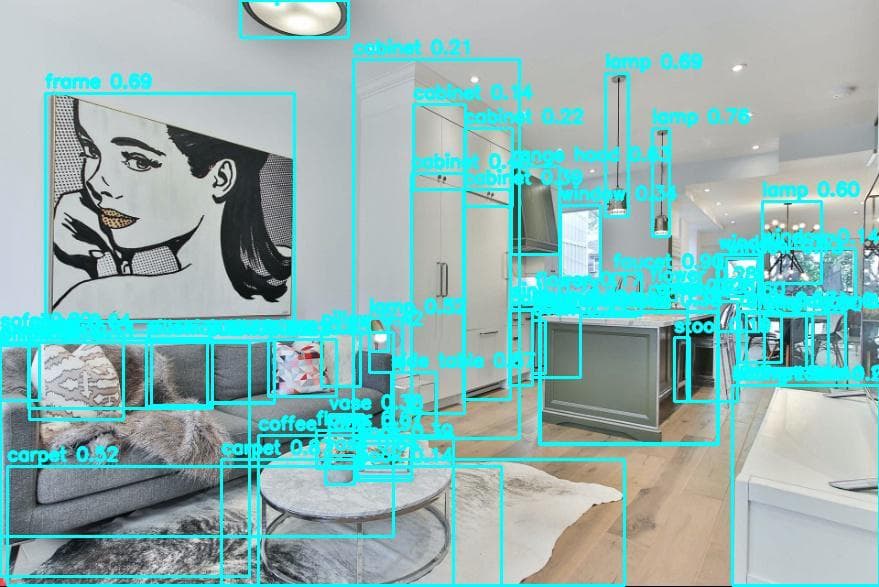
Kurat, RealSense D435i and Jetson Orin Nano on a four-wheel chassis
Kurat perception, YOLO detections with confidence, live indoor scene

Hardware

Animatronic head, eye, jaw and head servos driven over GPIO
Two-layer PCB, fabricated
OpenDroneKit, offline orthomosaic of the public Aukerman Park survey
OpenDroneKit, mission planning map and panels
OpenDroneKit, survey operations and reconstruction workspace

Team

Dreadnought Robotics, 120 members, 4 departments

Tooling

Continuum Extension, browser-native agent context panel
Continuum, local shared-memory control center

About

Most recently I replaced a company's ROS 1 architecture with a ROS 2 Humble stack for the SMR300, a 300 kg industrial AMR, LiDAR perception, PGV floor-tag localization, Nav2 navigation, CANopen and CiA 402 drives, and an operator platform for engineers who don't write code. It docks with 97% success and 2 cm mean error across 150 trials.

Languages: English, Hindi, Thai, Marathi.

Skills

Programming
C++ · Python · JavaScript · TypeScript · MATLAB
Robotics & Autonomy
ROS 2 Humble · ROS 1 · Nav2 · SLAM · tf2 · URDF · RViz · Gazebo · Localization · Path planning · Robot bringup · AMRs · MAVROS · MAVLink
Controls & Embedded
CANopen · CiA 402 · RS-485 · PID control · Sensor fusion · EKF / UKF · Raspberry Pi · Arduino · Pixhawk · Motor drivers · PCB design · KiCad
Perception & Vision
OpenCV · YOLOv8 · U-Net · PyTorch · TensorFlow · ORB-SLAM3 · COLMAP · RealSense D435i · LiDAR · PGV · SGBM · MiDaS
Embodied AI & Learning
Vision-Language-Action models · LeRobot · SmolVLA · LIBERO · Robot policy evaluation · Policy recovery · Robot agents · World action models · Grasp generation · MANO · Dexterous manipulation · MuJoCo · Experiment design · Simulation-based evaluation
Tools & Platforms
Linux · Docker · Git · Node-RED · PyQt6 · FEniCSx · Jetson Orin Nano · CUDA · TensorRT · MCP servers

Education

New York University · Tandon School of Engineering

Aug 2026, May 2028

M.S. Mechatronics and Robotics

Brooklyn, NY

Vellore Institute of Technology · VIT Chennai

2022, Jul 2026

B.Tech Computer Engineering, Robotics & AI Specialization

Chennai, India

Honors

  • 2nd Place, TAC Challenge Norway 2024 (2024)

    International autonomous underwater vehicle competition, Project MIRA.

  • Top 5 of 400, Smart India Hackathon 2024 (2024)

    National hardware and software innovation competition.

  • Top 30 of 500, Smart India Hackathon 2023 (2023)

    Autonomous VTOL search-and-rescue UAV.

  • 2nd Place, GEOFEST 2020, CMS Lucknow (2020)

    Geoscience festival at City Montessori School, Lucknow.

  • 50 attendees, KiCad PCB Design Workshop (2025)

    Led hands-on PCB layout training for engineering students.

  • 100+ students, Machine Learning Workshop (2024)

    Led an applied ML workshop for the university robotics community.